
How do I choose a DC drive?
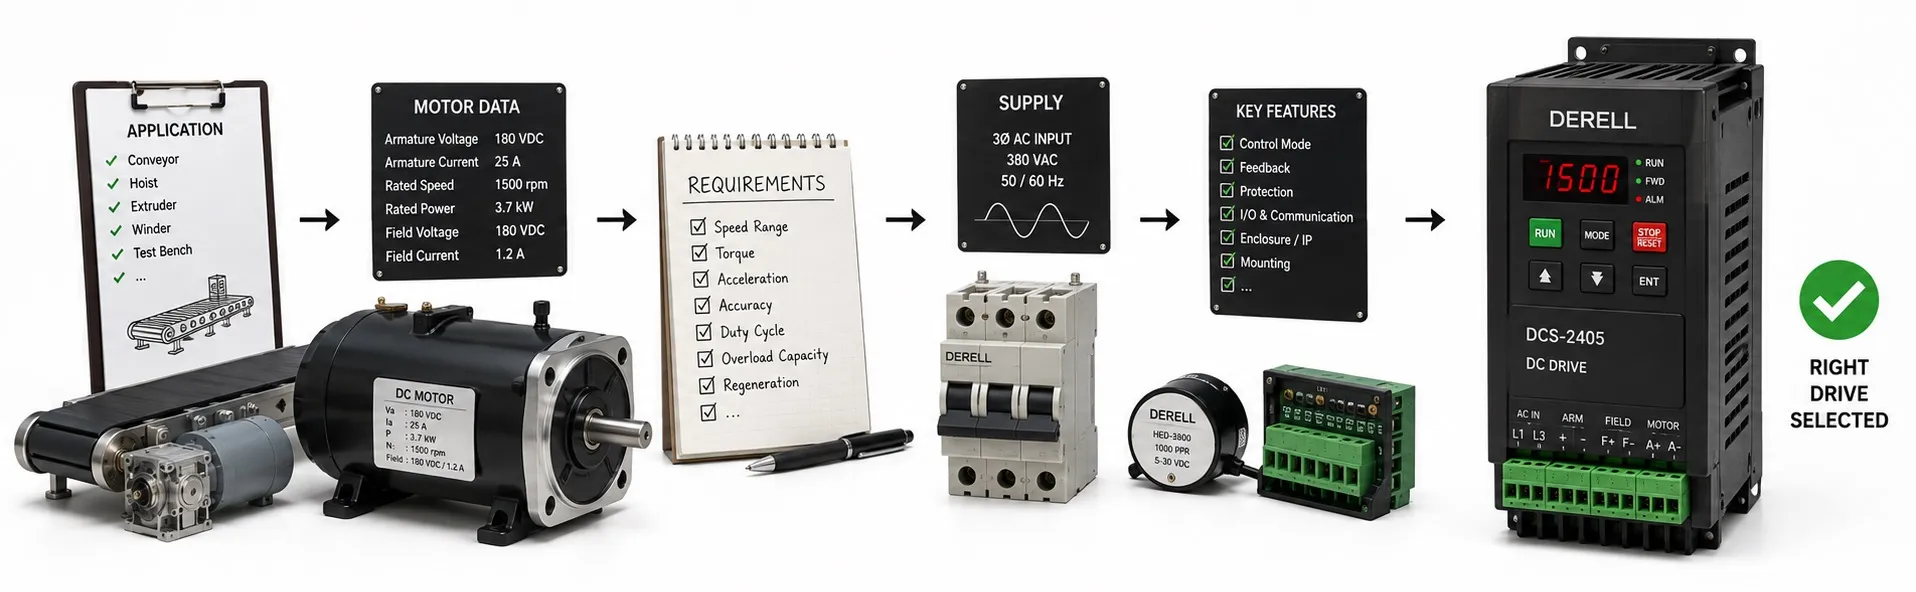
How do I choose a DC drive?
Hello, DC control enthusiasts,
Selecting a DC drive requires more than matching the motor's kW rating. Armature voltage and current, field supply, load torque, speed range and braking requirements must be assessed together. Two motors with the same power rating may require different drive currents if their rated voltages differ. The right DC drive must satisfy both the motor's electrical requirements and the machine's operating conditions.
Start with the motor type and nameplate
This selection method mainly applies to brushed DC motors. Permanent-magnet, separately excited and series-wound motors must not be treated as interchangeable. A BLDC motor also requires a controller that provides the appropriate electronic commutation, rather than a conventional DC armature drive. The first step is therefore to confirm motor and drive compatibility.
Record the motor's rated armature voltage, armature current, output power and speed. If it has a field winding, also record the field voltage and current. Identify any separately powered fan, temperature sensor, mechanical brake and speed-feedback device. Do not confuse the armature-current rating with the field-current rating.
Size the drive for continuous current and the duty cycle
The drive's continuous output-current capability under the actual installation conditions must cover the motor current required by the application. Continuous current alone is not enough: check the magnitude, duration and repetition rate of current peaks during starting, acceleration and load changes. A short-time overload rating is not a continuous operating rating.
Example: For a motor rated at 220 V DC and 40 A armature current, selecting a drive solely by its advertised kW rating is insufficient. The drive must provide the required armature voltage from the available supply and support the current demanded by the duty cycle. Multiplying the nameplate values gives 220 × 40 = 8,800 W of armature electrical input power; this is not the shaft output power. Motor losses and any separate field supply must be considered separately.
There is no universal rule to choose the next larger power size. Selection should follow the load's torque requirements and the manufacturer's duty-rating tables. Even with an oversized drive, motor-current limits and thermal-protection settings must be configured to protect the motor.
Check the mains supply and field supply separately
AC input voltage and DC motor voltage are different quantities. Verify the drive's single-phase or three-phase supply requirement, permitted mains-voltage range and available DC output voltage with that supply. In thyristor systems in particular, usable armature voltage depends on the mains supply, converter arrangement and operating conditions. Do not match the motor voltage solely against the highest output voltage shown in a catalogue.
For a separately excited motor, the field supply must have adequate voltage and current capability. A built-in field supply is not automatically suitable for every motor. Where necessary, use an external field unit supported by the manufacturer. A permanent-magnet motor has no separate field winding.
Assess speed range together with torque and cooling
Maximum speed is only part of the requirement. Also establish how long the motor must operate at minimum speed and under what load. A motor with a shaft-driven fan may receive inadequate cooling at low speed. Extended low-speed operation at high torque requires assessment of the motor's thermal capability and the possible need for independent ventilation.
Where field weakening allows operation above base speed, available torque generally decreases, and the motor's mechanical-speed and commutation limits still apply. A wide speed range does not mean that the same torque is available at every speed. Assess the required behavior against the drive's supported control methods.
Define reversing and braking requirements
A conveyor running in one direction has different requirements from a machine that frequently reverses or is driven by an overhauling load. Four-quadrant operation allows suitable torque control for motoring and electrical braking in both directions of rotation. Whether the system can return energy to the mains depends on the selected drive's power circuit and supply arrangement.
When comparing DC drive types, do not rely solely on a statement that a drive can reverse. Establish the stopping time, load inertia, braking frequency and direction of energy flow. Regenerative braking does not replace a mechanical brake required to hold a load safely.
Verify feedback and PLC compatibility
Basic speed adjustment and accurate low-speed regulation require different levels of performance. The drive's feedback options must match the installed encoder or tachogenerator. For an encoder, check supply voltage, signal type and resolution. For a tachogenerator, check its voltage-to-speed ratio and the drive's input limits. If position control is required, establish whether the drive or an external motion controller will perform it.
For PLC integration, the presence of an Ethernet or RS-485 connector is not enough. Verify the communication protocol, required option card, command and status data, analogue-reference range and electrical compatibility of the digital inputs.
Include cabinet conditions and the full installation cost
A drive physically fitting inside the cabinet is only the first check. Assess ventilation clearances, ambient temperature, altitude, dust and humidity. If the manufacturer requires current derating under these conditions, select the drive using its reduced capability. Include the required fuses, reactors, contactors, field unit and cooling equipment among the additional components in the installation cost.
Assess whether protection functions such as field-loss, overspeed, motor-temperature and feedback-loss monitoring meet the application's needs. Also consider parameter backup, documentation, spare parts and service support. Drive efficiency and motor efficiency are different: the drive conditions electrical power for the motor; conversion from electrical to mechanical energy takes place in the motor.