
How does a PID controller work?
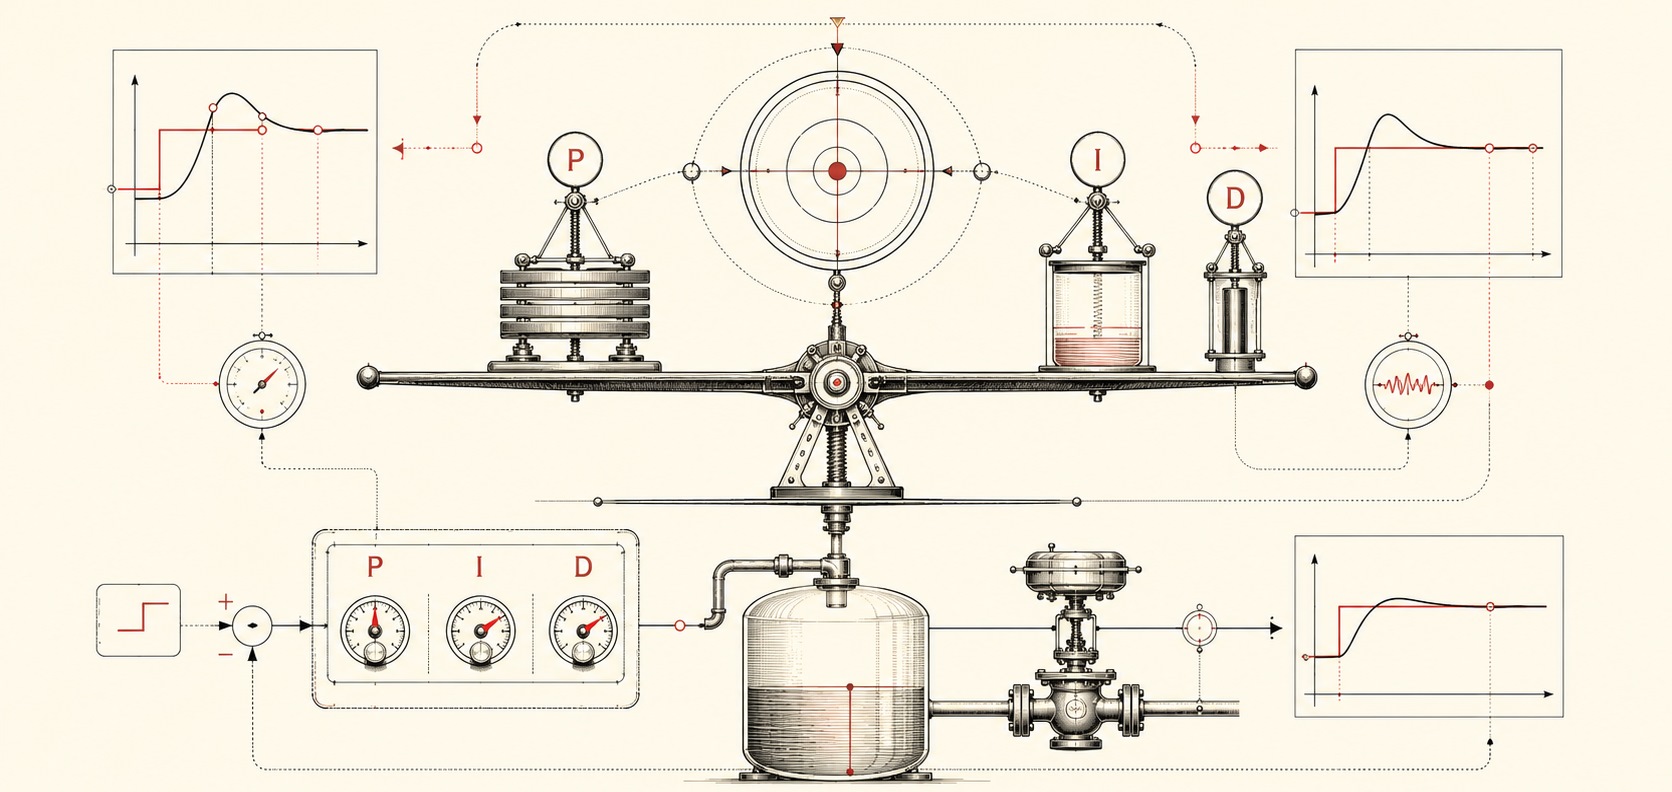
How Does a PID Controller Work in a Real Industrial Control Loop?
A PID controller does not control pressure, temperature or motor speed by itself. It sits inside a closed control loop where a sensor measures the process, the controller decides how much correction is required and an actuator changes the physical system.
A useful way to see the whole loop is:
Sensor → Measurement → PID calculation → Control output → Actuator → Process → New measurement
The controller repeats this sequence throughout operation.
The PID algorithm only knows the process through the measurement it receives. If the measurement is wrong, the controller will make the wrong correction for perfectly logical reasons.
For the basic definition and terminology, see What is PID?.
The Controller Needs a Target, a Measurement and Something It Can Change
Three values define most PID loops.
SP - Setpoint: where the process should operate.
PV - Process Variable: where the process is currently operating.
CV or MV - Control / Manipulated Variable: the output used to influence the process.
Consider a pump station required to maintain 6 bar pressure.
The setpoint is 6 bar.
A pressure transmitter supplies the actual pressure.
The controller output may become a speed reference to a variable-frequency drive.
If the process value falls to 5.3 bar, the controller detects the difference and increases the corrective output.
Error Is the Starting Point
A simple representation is:
Error = Setpoint - Process Value
PID uses this error, together with its time behaviour, to determine the control action.
But the three parts of PID do not react in the same way.
P - Proportional: responds mainly to the error that exists now.
I - Integral: responds to error that continues over time.
D - Derivative: responds to the rate at which the relevant signal is changing.
The separate roles of these terms are explained in the P, I and D components of PID control.
The PID Equation Is Only One Part of the System
One common parallel representation is:
Output = Kp × Error + Ki × ∫Error dt + Kd × d(Error)/dt

This equation is useful for understanding the controller, but it should not be assumed that every PLC, drive or process controller exposes its parameters in exactly this form.
Some controllers use Kp, Ki and Kd. Others use Kp, Ti and Td. Time units, derivative filtering and equation structure may also differ.
This is why PID settings should not be copied between unrelated controllers without checking the manufacturer's implementation.
For tuning details, see how Kp, Ki and Kd affect control performance.
What Happens During One Control Cycle?
1. The field sensor measures the physical process.
2. The controller receives and scales that measurement.
3. PV is compared with SP.
4. The controller calculates the required correction.
5. The result is limited to the usable actuator range.
6. The command is sent to a valve, VFD, heater, servo drive or another actuator.
7. The physical process responds.
8. The sensor measures the new condition and the cycle repeats.
In a digital controller, this calculation occurs at discrete time intervals. The execution period therefore becomes part of the control behaviour.
The Measurement Chain Matters as Much as the Algorithm
A PID controller may receive its process value from an analog transmitter, fieldbus instrument, encoder or another digital device.
For example, a 0-10 bar pressure transmitter may provide a 4-20 mA signal.
The controller must convert that electrical signal into the correct engineering value.
If the scaling is wrong, the PID loop operates on a false PV.
If the sensor is too slow, the controller receives old information.
If excessive input filtering is used, the displayed value may look smooth while the control loop becomes unnecessarily delayed.
Good PID control starts with a trustworthy measurement.
Pressure Control: A Classic Industrial Example
Consider a booster-pump system.
A pressure transmitter measures the line pressure. The setpoint is 5 bar. The PID output controls motor speed.
When plant demand increases, pressure begins to fall.
The controller increases its output.
The VFD increases pump speed.
The process pressure rises again.
As PV approaches the setpoint, the required correction decreases.
This application connects several of our related topics: PID pressure control, pressure measurement and PID control with a VFD.
Temperature Control Works on the Same Principle but on a Different Time Scale
An industrial oven also compares a measured value with a setpoint, but the physical response is usually much slower.
The heater may change power immediately while the temperature sensor sees the result much later.
Thermal mass stores energy, so temperature may continue rising after heater power has already been reduced.
That means tuning values suitable for a pressure loop should not simply be copied into a furnace controller.
For dedicated heating applications, see PID control with temperature controllers.
Flow Control: Fast Measurement, Fast Actuator
In a flow-control loop, a flowmeter provides PV and a valve or pump changes the flow.
Many flow loops respond faster than large temperature or level systems.
A suitable control loop may therefore require a shorter update interval and different tuning.
PID flow control deals specifically with this process behaviour.
Level Control Has Its Own Dynamics
Tank level is another common application, but it should not be treated as a slower version of pressure control.
If inlet flow remains greater than outlet flow, the level continues rising.
This integrating behaviour changes how the controller should be tuned.
For this reason, a PID setting copied from a pressure loop may perform poorly in PID level control.
Motor Speed Control Is Not Always the Same as Process PID
PID terminology is also used in motor-control systems.
A speed loop may compare requested speed with actual speed and generate a torque command.
In servo systems, position, velocity and current or torque loops can be nested and operate at different rates.
That structure is very different from a slow temperature controller or pressure transmitter feeding a pump PID.
See PID control with servo motors for the motion-control architecture.
Where Does the PID Calculation Actually Run?
The algorithm can run in many different industrial devices.
A PLC may execute the control loop and command a valve or drive.
A VFD may read a pressure transmitter directly and execute its own process PID.
A standalone temperature controller may control a heater without any PLC.
A servo drive may contain fast internal motion loops.
An industrial PC or microcontroller may also implement PID when its I/O and timing are suitable.
The important engineering decision is not merely whether the algorithm can run on a device, but whether that device is the correct place to close the loop.
PLC PID Is More Than a Function Block
When PID runs inside a PLC, the surrounding program has to manage more than Kp, Ki and Kd.
The application may also need:
input scaling,
periodic execution,
Auto / Manual mode,
output limiting,
sensor-fault handling,
integral windup protection,
actuator interlocks.
These practical details are covered in PID control with PLCs.
What Does SCADA Do in a PID System?
A SCADA system can display the process value, setpoint, controller output, mode and alarm state.
It can also trend SP, PV and CV so that engineers can see what the loop did during a disturbance.
However, the fact that PID values appear on a SCADA screen does not mean the fast control calculation runs on the SCADA server.
In many plants, the loop remains local in the PLC, RTU, drive or process controller while SCADA performs supervision.
The division of responsibilities is discussed in PID control with SCADA.
PID Must Run at an Appropriate Interval
Digital PID calculations occur at discrete intervals.
That interval should be suitable for the process dynamics.
A furnace whose temperature changes over minutes gains little from calculating a new PID output every millisecond.
A fast pressure or flow loop may require significantly more frequent updates.
Irregular execution can also change integral and derivative behaviour.
This is why time delay and process dynamics are part of controller design rather than a separate theoretical subject.
What Happens When the Output Reaches Its Limit?
Every actuator has a physical limit.
A valve cannot open beyond its full travel.
A heater cannot produce more than its rated power.
A VFD cannot command unlimited motor speed.
If the PID output reaches the limit while the error remains, the controller can no longer create additional physical correction.
This is called output saturation.
If integral action continues building during saturation, integral windup can develop.
The stored integral contribution may later produce severe overshoot when the process returns to a controllable region.
Practical PID implementations therefore commonly provide output limits and anti-windup behaviour.
Manual Mode Helps Prove the Process Before Automatic Control
During commissioning, Manual mode is valuable because it separates PID behaviour from actuator and process behaviour.
For example, command a pump to a modest fixed speed.
Does the motor reach the requested speed?
Does pressure move in the expected direction?
Does the transmitter report that pressure correctly?
How long before the process begins to respond?
If these answers are unknown, automatic PID tuning is premature.
After Manual operation is understood, Automatic mode can close the loop.
Where supported, tracking or bumpless transfer can prevent a large output jump during the change from Manual to Auto.
PID Is Widely Used, but Full PID Is Not Always Required
Many industrial loops operate as PI controllers with no derivative term.
Pressure, flow and temperature applications frequently work very well with P and I only.
Derivative action should be enabled because the process benefits from it, not because the abbreviation contains the letter D.
Likewise, some motion systems use P or PI structures in individual loops while combining them with feedforward and model-based functions.
The correct control structure is the one required by the plant, not the one containing the largest number of terms.
Where PID Is Commonly Used in Industry
Pressure: pumps, compressors, pneumatic systems and process pipelines.
Temperature: ovens, furnaces, extruders, boilers, HVAC and process vessels.
Flow: liquid, gas, dosing and utility systems.
Level: tanks, reservoirs and process vessels.
Speed: pumps, fans, conveyors and rotating machinery.
Motion: servo axes, positioning machines and robotic systems.
Process chemistry: pH, concentration and related measurable variables.
Environmental control: temperature, humidity, airflow and pressure.
The feedback concept is shared, but the measurement technology, physical dynamics and actuator are different in each case.
When a PID Loop Performs Badly
Do not assume immediately that the gains are wrong.
PV is unstable while the physical process is steady: inspect the sensor, wiring, scaling and filtering.
CV changes but the process does not: inspect the actuator, VFD, valve or mechanical equipment.
CV remains at maximum but SP is never reached: inspect process capacity.
The loop oscillates: investigate gains, delay, integral action and process dynamics.
The process overshoots badly: check integral behaviour, stored process energy and dead time.
The same tuning behaves differently at different production rates: plant dynamics may change with operating point.
For systematic diagnosis, see common PID problems and troubleshooting.
Is PID the Only Feedback Strategy?
No.
PID remains extremely useful because it combines good performance with reasonable complexity.
But processes with large dead time, measurable disturbances, strongly changing dynamics or several interacting variables may benefit from feedforward, cascade control, gain scheduling, adaptive control or model-based approaches.
These methods often supplement PID rather than simply replacing it.
See PID and other control strategies for the comparison.
A Useful Commissioning Check
1. Is the sensor measuring the real process correctly?
2. Is the measurement scaled correctly?
3. Are SP and PV in compatible engineering units?
4. Does the actuator respond in Manual mode?
5. Does the process move in the expected direction?
6. Are output limits realistic?
7. Is the control loop executing at a suitable interval?
8. Is excessive filtering or communication delay present?
9. Does the actuator reach saturation?
10. Can SP, PV and CV be trended together?
If several of these questions are unanswered, tuning should probably wait.
Related PID Operation and Application Topics
PID fundamentals: What Is PID? - P, I and D Components - PID Gain and Tuning
Dynamics and troubleshooting: Time Delay and Process Dynamics - Stable PID Operation - PID Troubleshooting
Industrial platforms: PID with PLCs - PID with VFDs - PID with SCADA - PID with Servo Motors
Process applications: Pressure Control - Flow Control - Level Control - Temperature Control
Beyond basic PID: PID and Other Control Strategies
Industrial PID implementations differ in equation form, parameter units, derivative treatment, sample time, output limiting, anti-windup and Manual/Auto transfer. Configuration should always be checked against the documentation for the actual PLC, drive or process controller being used.