
invt Servo Fault codes DA200
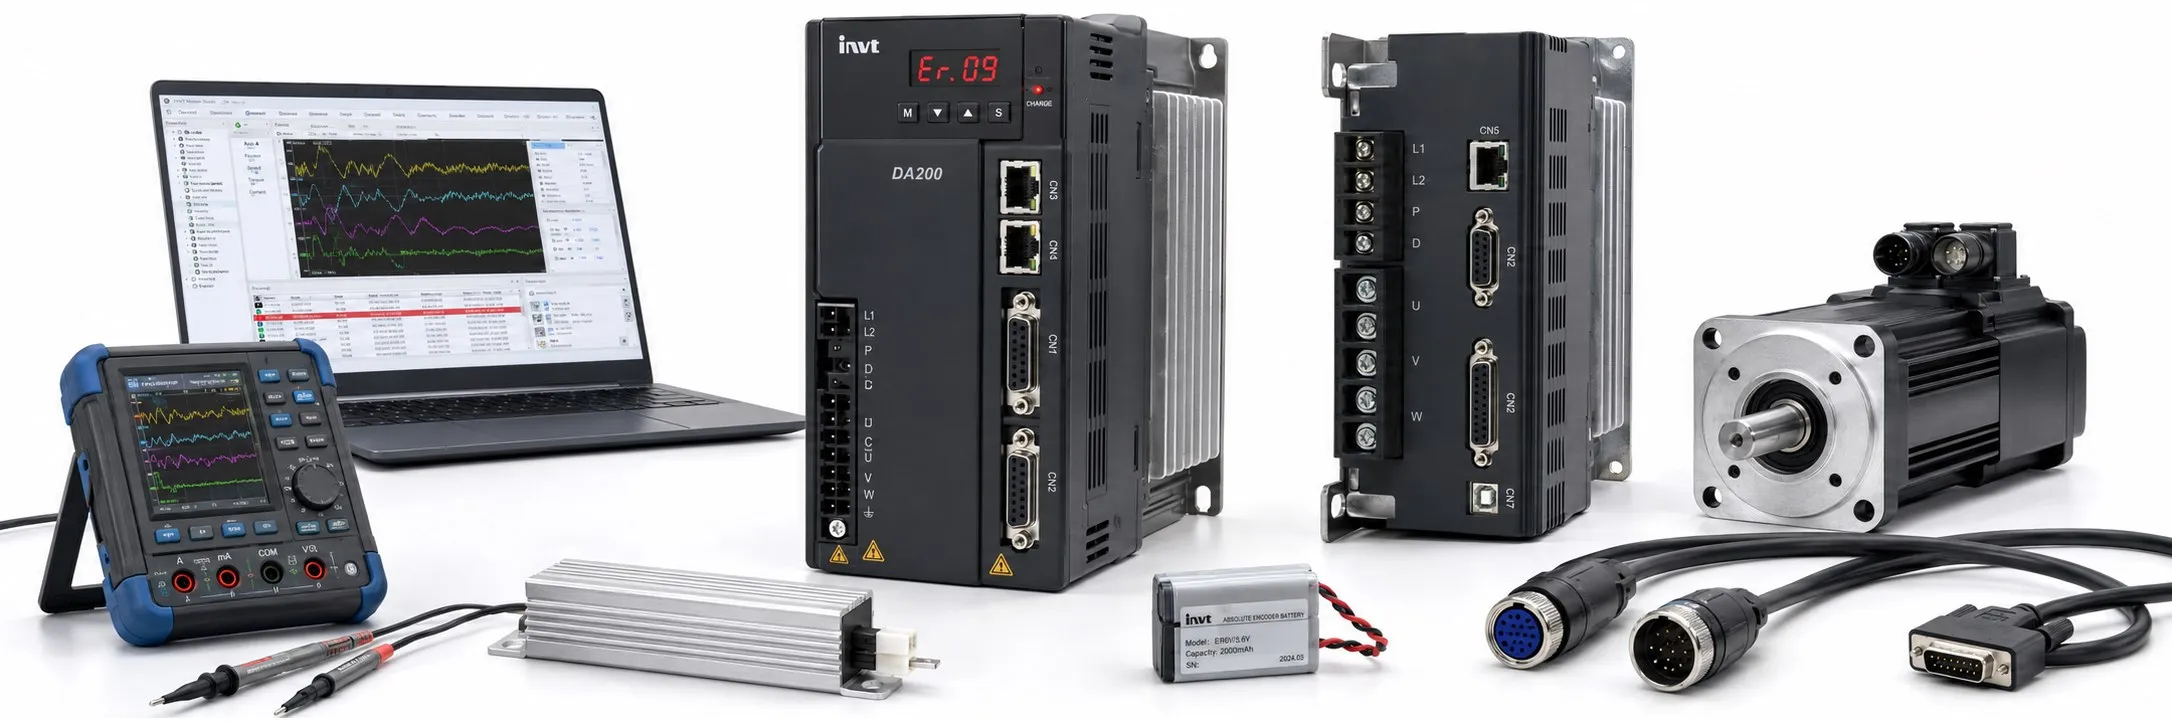
INVT DA200 Servo Fault Codes
INVT DA200 servo drive fault codes help identify problems related to the power stage, encoder feedback, current sensors, parameter settings, I/O configuration, communication networks, motor load, speed control and positioning.
Use the read more >> link beside each code to open the corresponding detailed DA200 fault page with additional troubleshooting information.
Er01-0 - IGBT fault (read more >>)
Er01-1 - Braking transistor fault (7.5 kW and above models) (read more >>)
Er02-0 - Encoder fault - Encoder cable disconnected (read more >>)
Er02-1 - Encoder fault - Encoder feedback error too large (read more >>)
Er02-2 - Encoder fault - Parity error (read more >>)
Er02-3 - Encoder fault - CRC error (read more >>)
Er02-4 - Encoder fault - Frame error (read more >>)
Er02-5 - Encoder fault - Short frame error (read more >>)
Er02-d - Encoder fault - EEPROM data check error (read more >>)
Er03-0 - Current sensor fault - U-phase IGBT fault (read more >>)
Er03-1 - Current sensor fault - V-phase IGBT fault (read more >>)
Er03-2 - Current sensor fault - W-phase IGBT fault (read more >>)
Er04-0 - System initialization fault (read more >>)
Er05-1 - Setting fault - Motor model error (read more >>)
Er05-2 - Setting fault - Motor and drive model error (read more >>)
Er05-3 - Setting fault - Software limit setting error (read more >>)
Er05-4 - Setting fault - Homing mode setting fault (read more >>)
Er05-5 - Setting fault - Position control overflow fault (read more >>)
Er07-0 - Regeneration discharge overload fault (read more >>)
Er08-0 - Analog input overvoltage fault - Analog input 2 (read more >>)
Er08-1 - Analog input overvoltage fault - Analog input 3 (read more >>)
Er08-2 - Analog input overvoltage fault - Analog input 3 (read more >>)
Er09-0 - EEPROM fault - Read/write fault (read more >>)
Er09-1 - EEPROM fault - Data check fault (read more >>)
Er10-0 - Hardware fault - FPGA fault (read more >>)
Er10-1 - Hardware fault - Communication card fault (read more >>)
Er10-2 - Hardware fault - Ground short-circuit fault (read more >>)
Er10-3 - Hardware fault - External input fault (read more >>)
Er10-4 - Hardware fault - Emergency stop fault (read more >>)
Er10-5 - Hardware fault - RS485 communication fault (read more >>)
Er11-0 - Software fault - Motor control task re-entry (read more >>)
Er11-1 - Software fault - Repeated task (read more >>)
Er11-2 - Software fault - Illegal operation (read more >>)
Er12-0 - I/O fault - Duplicate digital input assignment (read more >>)
Er12-1 - I/O fault - Duplicate analog input assignment (read more >>)
Er12-2 - I/O fault - Pulse input frequency too high (read more >>)
Er13-0 - Main circuit overvoltage fault (read more >>)
Er13-1 - Main circuit undervoltage fault (read more >>)
Er14-0 - Control power undervoltage fault (read more >>)
Er17-0 - Drive overload fault (read more >>)
Er18-0 - Motor overload fault (read more >>)
Er18-1 - Motor overtemperature fault (read more >>)
Er19-0 - Speed fault - Overspeed fault (read more >>)
Er19-1 - Speed fault - Forward overspeed fault (read more >>)
Er19-2 - Speed fault - Reverse overspeed fault (read more >>)
Er19-3 - Speed fault - Overspeed parameter setting error (read more >>)
Er20-0 - Speed deviation fault (read more >>)
Er21-0 - Position overtravel - Forward overtravel (read more >>)
Er21-1 - Position overtravel - Reverse overtravel (read more >>)
Er22-0 - Hybrid control deviation too large (read more >>)
Er22-1 - Position increment overflow fault (read more >>)
Er22-2 - Position increment overflow fault (read more >>)
Er22-3 - CANopen fault - Sync signal timeout (read more >>)
Er22-4 - CANopen fault - Position command buffer full (read more >>)
Er23-0 - Drive overtemperature fault (read more >>)
Er24-0 - PROFIBUS-DP fault - PWK parameter ID error (read more >>)
Er24-1 - PROFIBUS-DP fault - PWK parameter outside range (read more >>)
Er24-2 - PROFIBUS-DP fault - PWK parameter is read-only (read more >>)
Er24-3 - PROFIBUS-DP fault - PZD configuration parameter does not exist (read more >>)
Er24-4 - PROFIBUS-DP fault - PZD configuration parameter attributes do not match (read more >>)
Er25-4 - Application fault - Encoder offset angle test timeout (read more >>)
Er25-5 - Application fault - Encoder offset angle test failure (read more >>)
Er25-6 - Application fault - Homing position error (read more >>)
Er25-7 - Application fault - Inertia identification failure (read more >>)
Er26-0 - CANopen fault - CANopen connection lost (read more >>)
Er26-1 - CANopen fault - SDO index does not exist (read more >>)
Er26-2 - CANopen fault - SDO sub-index does not exist (read more >>)
Er26-3 - CANopen fault - SDO data length error (read more >>)
Er26-4 - CANopen fault - SDO write data outside range (read more >>)
Er26-5 - CANopen fault - Read-only parameter cannot be modified (read more >>)
Er26-6 - CANopen fault - PDO mapping length error (read more >>)
Er26-7 - CANopen fault - PDO mapping data does not exist (read more >>)
Er26-8 - CANopen fault - PDO cannot be changed during operation (read more >>)
Er26-9 - CANopen fault - PDO mapping not permitted (read more >>)
Er26-a - CANopen fault - Sync signal too fast (read more >>)
Er26-b - CANopen fault - Receive error (read more >>)
Er26-c - CANopen fault - Send error (read more >>)
Er26-d - CANopen fault - Repeated sync signal (read more >>)
Er26-e - CANopen fault - Bus load rate too high (read more >>)
Er26-f - CANopen fault - Parameter modification state error (read more >>)
INVT DA200 Fault Code Document
+ INVT DA200 Servo Fault Codes (PDF)
Related INVT Servo Pages
+ INVT DA200 Servo Fault Code Index