
What is the measurement range of the tachometer?
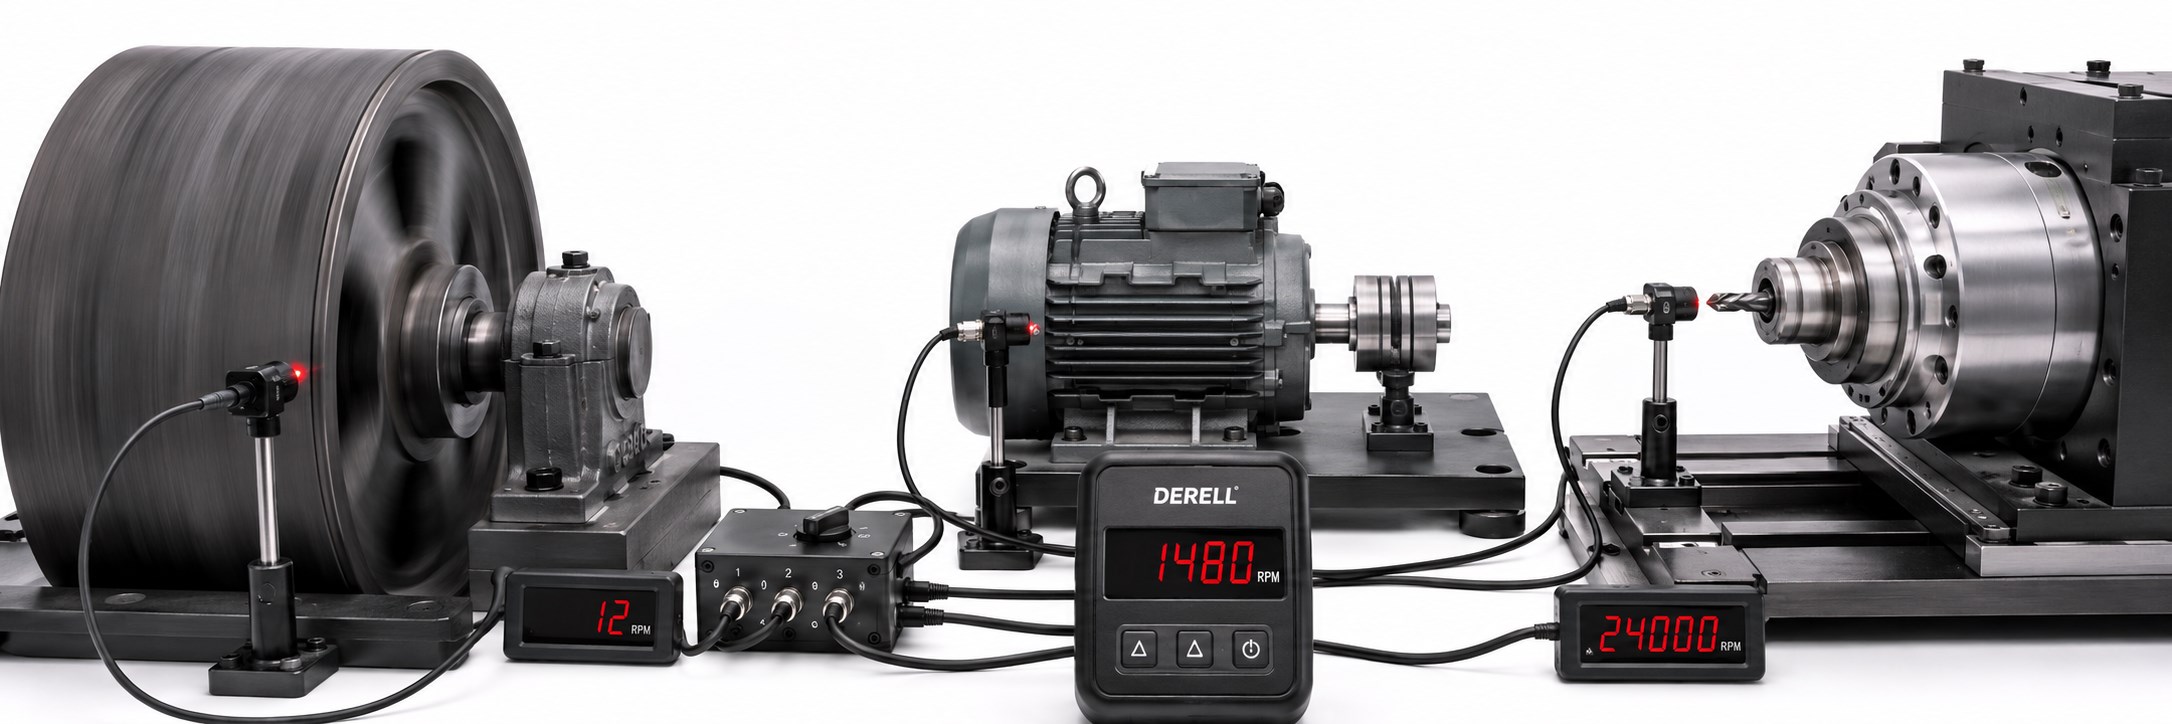
Finding the speed limits that matter for your installation
A tachometer's measurement range is the interval between its lowest and highest measurable rotational speed under specified conditions. It is usually expressed in RPM, although instruments may also report revolutions per second, period or surface speed. There is no universal range for all tachometers: sensing method, operating mode and configuration determine the usable limits.
Start with the correct operating mode
For a documented example, the HIOKI FT3405/FT3406 specifications list 30–99,990 RPM for non-contact measurement and 15–19,999 RPM for contact measurement with averaging enabled. Disabling averaging changes the lower limits. These are model- and mode-specific figures, rather than standard ranges for handheld tachometers. Contact adapters remain subject to their mechanical limits and the manufacturer's operating instructions.
Range does not establish accuracy. Being able to display 10,000 RPM does not mean the error is identical throughout the operating range. Read accuracy and precision specifications alongside the relevant subrange, resolution and averaging setting. A 0.1 RPM display increment is not, by itself, a ±0.1 RPM accuracy guarantee. The same distinction applies when comparing analog and digital instruments.
A frequency limit must be converted into shaft speed
For a pulse-input instrument, the important limit may be specified in hertz. Let n be RPM, P the number of pulses actually counted per revolution, and f the input frequency. Then f = n × P / 60 and n = 60 × f / P. A shaft turning at 1500 RPM with 60 counted pulses per revolution supplies a 1500 Hz signal.
| Counted pulses/rev | Frequency-derived RPM ceiling |
|---|---|
| 1 | 60,000 RPM |
| 60 | 1000 RPM |
| 100 | 600 RPM |
These figures are frequency-derived ceilings only, not approved instrument ranges or safe mechanical speeds. The actual upper limit also depends on sensor compatibility, the instrument's RPM limit and mechanical constraints. In this hypothetical example, 60 pulses/rev at 1500 RPM exceeds the 1000 Hz input rating.
The complete pulse path has to keep up
Check the sensor switching frequency as well as the indicator input rating. An inductive sensor, photoelectric sensor or Hall sensor must supply pulses with suitable high and low durations. Excessive input filtering can reject short pulses. Poor sensing distance or target geometry during installation can cause missed pulses even below the nominal frequency limit.
Pulses-per-revolution scaling must match the received signal. Feeding 60 pulses per turn into an instrument configured for one pulse per turn ideally produces a reading 60 times too high. With encoders, channel PPR and ×2/×4 edge counting are different quantities: use the event count that the instrument actually processes. Adding reflective marks to a single-mark optical instrument without adjustable scaling will not produce a correctly scaled speed reading.
The lower limit is also a timing problem
At 6 RPM with one pulse per revolution, successive pulses arrive 10 seconds apart. At the same speed with 60 pulses per revolution, the interval falls to approximately 167 ms. Neither figure is the complete response time; each describes pulse spacing. At very low speeds, the calculation method, averaging and no-pulse timeout affect usable performance. An overly short timeout can declare a slowly moving shaft stationary.
Output scaling is another, separate range
If an instrument provides a 4–20 mA or 0–10 V output, establish which RPM values correspond to its endpoints. For example, 4–20 mA mapped to 0–3000 RPM describes an application scale, not necessarily the instrument's full measuring capability. Configure the receiving PLC consistently. For communication-based readings, confirm the unit, decimal multiplier and register representation.
A practical selection check
Define the lowest operating speed, highest speed and expected overspeed. Calculate input frequency from the counted pulses per revolution, then compare it with both sensor and instrument limits. Check low-speed update behaviour, the accuracy conditions and any adapter or accessory restrictions. Choose for the actual application rather than the largest headline RPM number.
If readings overflow or appear unexpectedly low, begin troubleshooting with scaling, input frequency and filter settings, then inspect the sensor's maintenance condition. The best range is the one that covers your process with adequate accuracy and response.
Technical reference: HIOKI FT3405/FT3406 instruction manual: operating modes and range tables