
what is hall sensor?
Hall-effect sensors: what they detect and how to choose one
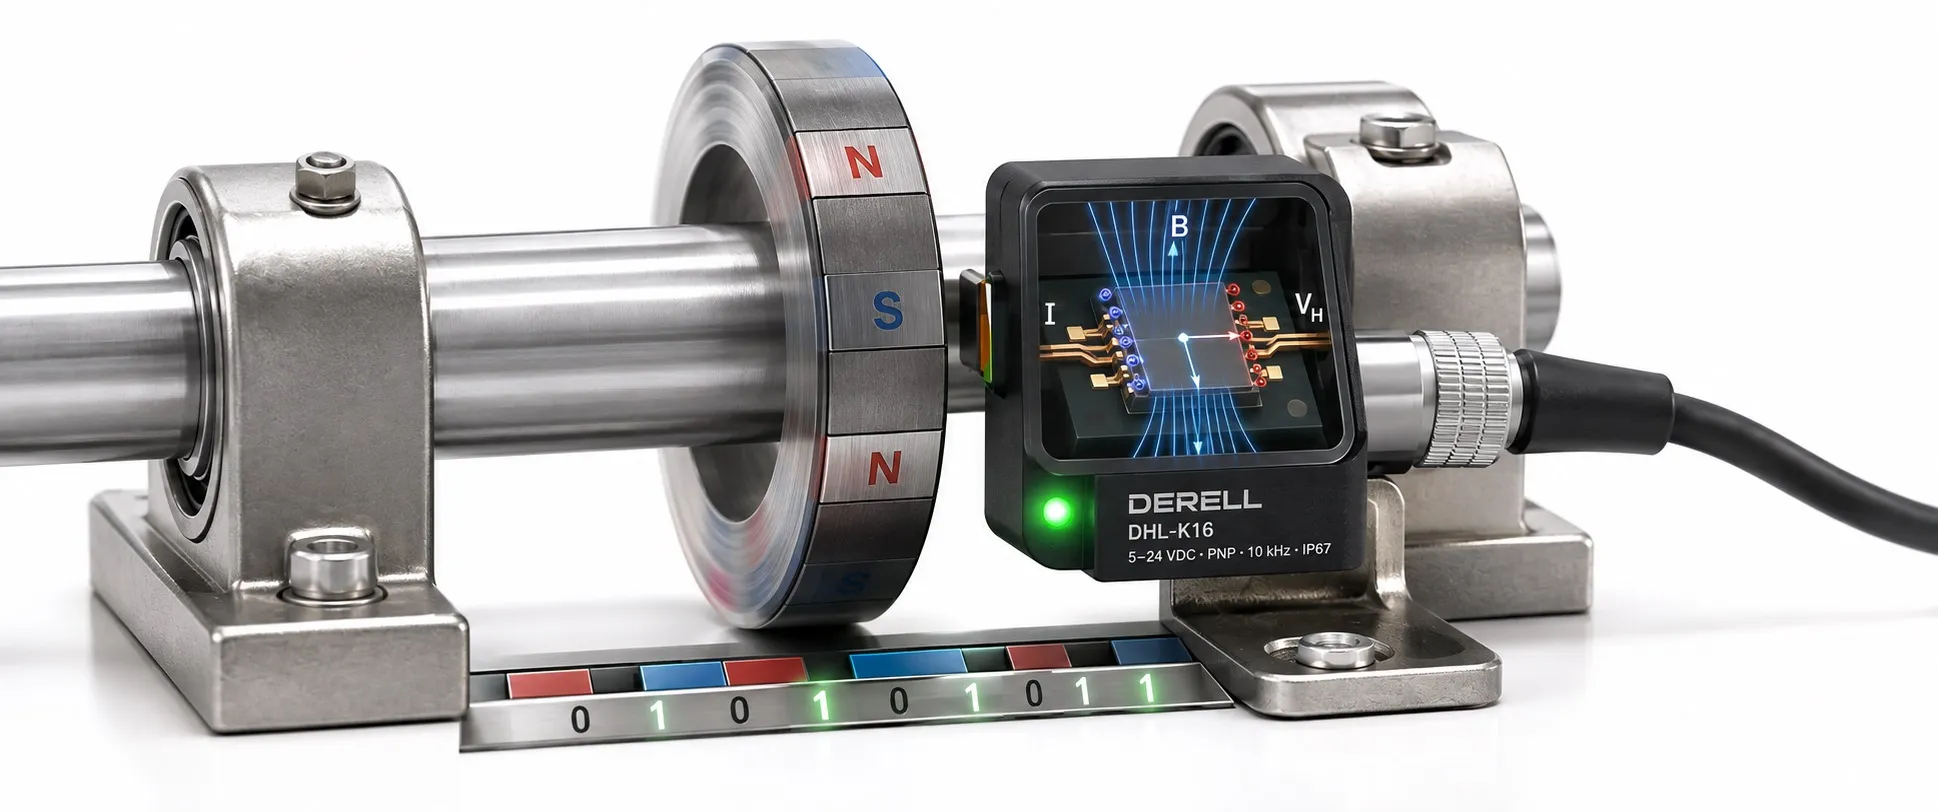
A Hall-effect sensor responds to magnetic flux density and converts it into an electrical output. Depending on the magnet arrangement and signal processing, that output can represent position, angle or speed. A current-sensing design instead uses the field produced by a conductor. The underlying measurement is magnetic; a basic Hall element does not directly read shaft speed or mechanical distance. Sensor fundamentals explains the wider context. [1]
It is not normally an electron-density meter. Laboratory Hall measurements can be used to calculate a material’s charge-carrier concentration, but that is a different measurement task from detecting a magnet in a machine. Keep the industrial device separate from that laboratory use of the Hall effect. [3]
A magnetic field becomes a voltage
An electrically biased Hall element carries a current. A magnetic field in the appropriate direction deflects the moving charge carriers, producing a transverse Hall voltage. Amplification and processing turn that small voltage into a usable signal. The magnet is not a replacement for the sensor’s power supply. [2]
Orientation matters as much as field strength. Check the sensitive axis and polarity convention in the data sheet, rather than assuming any face of the package will respond equally. Flux density is commonly given in millitesla or gauss; 1 mT = 10 gauss. Hall sensing can respond to a static field, so movement is not an inherent requirement of the principle. [4] [1]
Choose the output behaviour before comparing part numbers
Linear analog output: Within its specified range, the output changes approximately linearly with the measured field component. “Analog” describes the interface; “linear” describes the transfer characteristic. These labels overlap. A continuous analog signal can be useful for measurement, but linearity with magnetic field does not guarantee linearity with distance from a magnet. [17] [10]
Magnetic switch: The output changes at an operate point and returns at a separate release point. A unipolar switch responds to one polarity; an omnipolar switch can respond to either. The separation between operate and release thresholds creates hysteresis, reducing repeated transitions near the switching boundary. [5]
Bipolar latch: One field polarity sets a state; a sufficiently strong opposite polarity resets it. Moving the magnet away may leave the output unchanged. State retention while powered is not a promise of non-volatile memory. Check the startup behaviour rather than assuming the previous state survives a power cycle. [7]
Digital measurement: A digital Hall device need not be a one-bit switch. For example, the TMAG5170 measures three magnetic axes and communicates through SPI. With suitable magnetic geometry and processing, multi-axis measurements can support angle sensing and Hall-effect encoders. Raw X/Y/Z magnetic values are not automatically a complete mechanical position measurement. [8]
Programmable or application-specific: Depending on the product, sensitivity, offset, temperature compensation or the output format can be configured. A sensor may be linear and programmable at the same time. Application-specific does not automatically mean fewer functions, nor does it prove that the component cannot be used elsewhere. Its complete specification decides suitability. [9]
Two examples that make the output easier to interpret
Switching example: Assume a unipolar switch operates at 6 mT and releases at 4 mT. On the way up from zero, it has not yet operated at 5 mT. After passing 6 mT, however, it remains active when the field falls back to 5 mT; release occurs at the lower threshold. The same field can give different output states because of its recent history. These are illustrative thresholds, not a particular device specification.
Linear-output model: A useful simplified relationship is Vout = VQ + S × B, where VQ is the zero-field output, S is sensitivity and B is the signed field component. Some ratiometric sensors centre their output near half the supply voltage; others do not. Read the specified transfer function. [4]
For an assumed VQ of 1.65 V and sensitivity of 30 mV/mT, a field of +10 mT gives 1.95 V; −10 mT gives 1.35 V, provided both points are within the linear range. Zero field need not mean zero volts. These numbers demonstrate the calculation and are not a model recommendation.
Hall, inductive and reed devices are not interchangeable
A conventional inductive proximity sensor generates a changing field with a coil and detects the influence of eddy currents in a metal target. A Hall sensor detects magnetic flux density. Importantly, an active inductive proximity sensor can detect stationary metal; it should not be confused with a passive speed pickup that depends on movement. [12]
Hall systems can also detect ferromagnetic targets. An integrated or external back-bias magnet provides a field that a steel gear modifies. The Hall element still measures the magnetic field, rather than detecting every unmagnetised metal on its own. Use the detection-method comparison to assess the actual target and interface requirements. [11]
A reed switch uses mechanically moving magnetic contacts; a Hall IC uses semiconductor sensing and electronics. The Hall-versus-reed comparison matters electrically as well as mechanically. Responding to the same magnet does not establish matching supply, load or output requirements. [13] [15]
From magnetic pulses to shaft speed
For a shaft producing P counted events per mechanical revolution at an event frequency of f hertz, speed is n = 60 × f / P. Suppose one channel delivers six rising edges per revolution and the measured frequency is 150 Hz. The result is 1,500 RPM. P is the number of events your counter actually counts, not automatically the number of magnets. Counting both edges changes that definition.
This principle supports speed monitoring. A simple single-channel periodic pulse train does not, by itself, reveal direction. Phase-related channels or suitable coding provide additional information. Hall signals used for motor commutation should not be assumed equivalent to high-resolution encoder feedback; the optical-versus-magnetic encoder guide explores the broader choice. [5] [16]
Current measurement uses a different magnetic arrangement. A Hall current sensor measures the field generated by current in a conductor. Suitable designs measure DC as well as AC. Range, bandwidth, offset and galvanic isolation remain separate specifications. A Hall-based circuit board is not automatically suitable for a high-voltage measurement. Respect the complete product’s insulation and installation limits. [14]
Getting a valid signal into the controller
A bare IC is not a 24 V industrial sensor. For example, the DRV5032 operates from 1.65–5.5 V; applying 24 V directly is outside that supply range. Before connecting a device to a PLC, check the supply, signal thresholds and whether an interface stage is needed. [6]
Open-drain output: A suitable pull-up resistor establishes the high level; the active output pulls low. Both the pull-up voltage and current must remain within the sensor and receiver ratings. A push-pull output behaves differently. Review PNP/NPN compatibility, NO/NC logic and connector pin assignments separately rather than treating them as alternative names for the same feature. [15] [6]
Selection and troubleshooting checks
Check the magnetic assembly. Sensitive-axis alignment, polarity, air gap, temperature and nearby ferromagnetic parts all affect the field seen by the sensor. A stronger magnet can saturate a linear measurement or prevent a switch from releasing at the intended position. Suitable mounting accessories and stable mechanical positioning are part of the design. [10] [11]
Check the complete timing path. A slowly sampled Hall switch can miss a brief magnet passage. Evaluate pulse width, sensor updates, counting frequency and the receiving input filter together. “Digital” does not mean “fast”. [6]
When the output appears stuck: Verify power and pinout, then test the specified pole against the correct sensing face. For a latch, check the opposite-pole reset condition; for open-drain, check the pull-up. Use a suitable waveform instrument for fast pulses rather than relying only on a multimeter’s averaged indication. An unpowered resistance check is not a complete Hall-sensor test. Isolate the circuit safely before changing connections.