
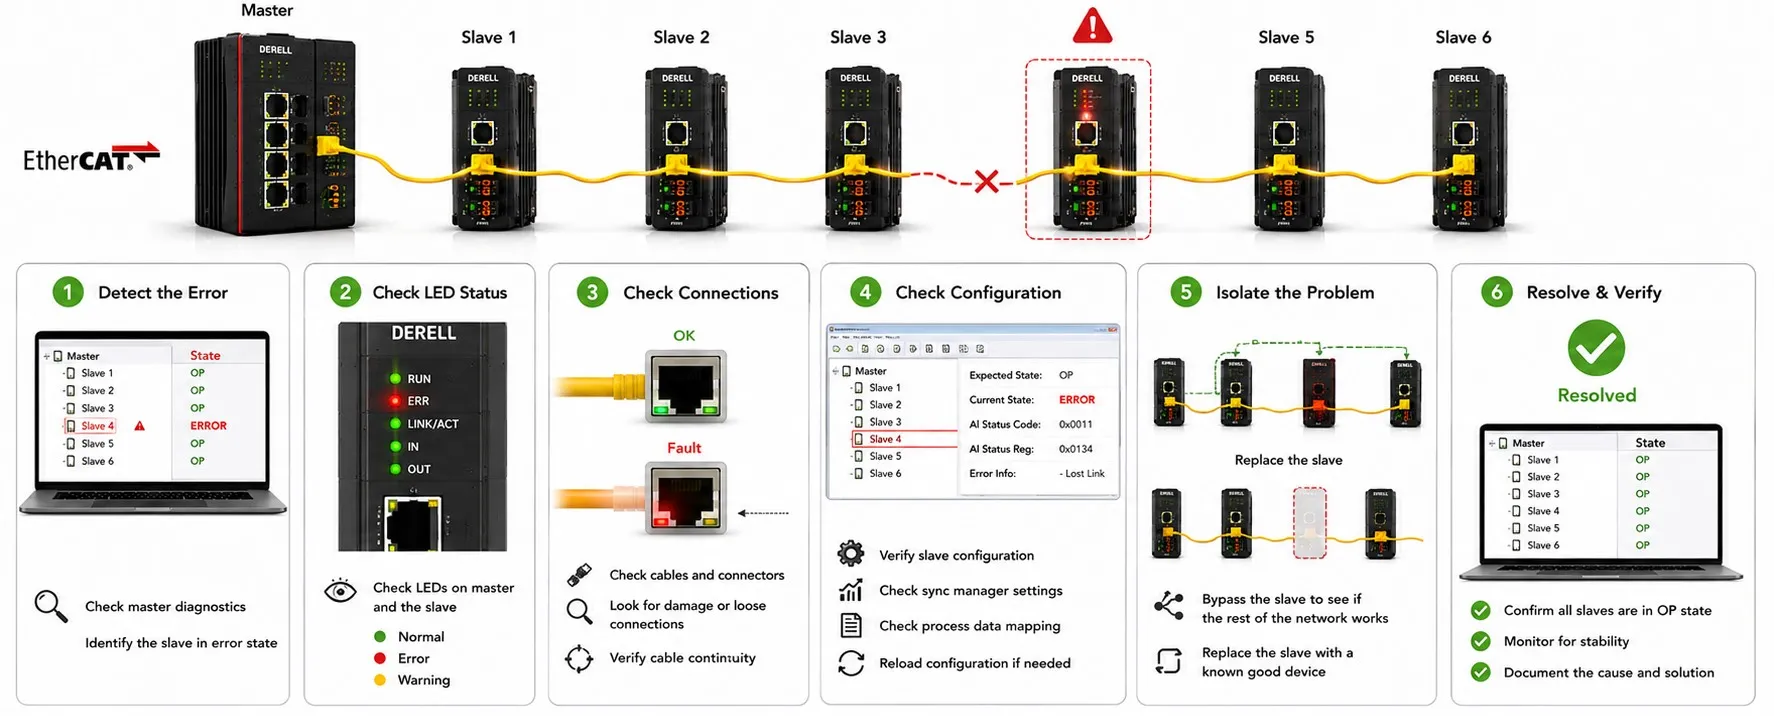
How can you detect and resolve an error in an EtherCAT network?
The fastest way to troubleshoot EtherCAT is not to replace cables at random or reset the complete machine. It is to narrow the fault by evidence and by layer. Start with a few questions: Is the whole network missing, does the fault begin after one device, which EtherCAT state failed, is the Working Counter valid, are link/error counters increasing, and does the configured ESI/PDO/DC setup match the real device? Those questions separate physical faults from configuration and application problems.[1]
Preserve the evidence before you reset anything. Record the failing device's state, AL Status/Code, WKC/WcState, port-link condition, lost-frame/error counters and topology view before clearing counters, power-cycling the device or reloading the project. A reset can make the symptom disappear while also erasing the best evidence of the root cause.
First decide how large the fault is
Ask whether no SubDevices are visible, whether the network disappears after one node, or whether every device is present but process data is invalid. If nothing is visible, check the MainDevice's selected NIC, driver and first physical link. If all devices after one node are missing, the topology and that node's port/cable become strong suspects. If all devices are visible, move upward to PDO, WKC, watchdog, synchronization or application data.
Do not confuse the PC's communication interface with an EtherCAT station identity. Selecting the wrong Ethernet NIC is a different problem from having the wrong SubDevice position or configured address.
Use the LEDs as the first clue, not the final diagnosis
RUN, ERR and LINK/ACT LEDs are useful. No link can indicate cable, connector, power or port trouble. A powered device that never reaches OP is more likely to have a configuration or state-machine problem. But an LED only shows a local condition; always pair it with the MainDevice diagnostic view.
The image above deliberately follows the useful field sequence: status → connection → configuration → isolation → verification.
Find the EtherCAT State Machine transition that failed
SubDevices normally progress through INIT → PREOP → SAFEOP → OP. Delta Motion's current diagnostic view shows both the current and requested/target state and states that a network failing to reach the target state has SubDevice errors preventing that transition. During troubleshooting, temporarily requesting a lower state and then stepping upward again can help identify where the transition fails.[2]
A device stuck in PREOP points you toward identity, ESI, mailbox or startup configuration. A device that reaches SAFEOP but not OP often directs attention toward SyncManager/PDO, watchdog or synchronization settings. These are diagnostic directions, not substitutes for reading the actual AL Status Code.
Read the AL Status Code before changing hardware
A generic “SubDevice ERROR” message is too broad. The AL Status Code or the vendor's corresponding diagnostic text can tell you why an ESM transition was refused. Different causes—PDO/SyncManager mismatch, watchdog condition, synchronization timing or local device fault—can look similar from the outside.
The efficient workflow is read code → interpret against the vendor/ETG documentation → correct the relevant configuration → retry the state transition. Replacing a device first is wasteful when the fault is in the project configuration.
WKC / WcState tells you whether cyclic process-data participation is valid
The Working Counter validates whether the expected EtherCAT memory interactions actually took place. Beckhoff documents WcState=0 as valid real-time communication in the last cycle and WcState=1 as invalid communication. It also warns that input data can remain frozen at the last valid value while communication is invalid.[3]
This is a major troubleshooting trap. An analog value can still display “37.2” while no new measurement is arriving. When checking a sensor, encoder or servo feedback, verify the communication-validity state as well as the engineering value.
Lost-frame and port-error counters expose intermittent physical faults
MainDevice statistics can report lost or invalid cyclic and acyclic frames. Beckhoff's frame-statistics interface separates cyclic frames, lost cyclic frames, queued frames and lost queued frames. Other Beckhoff diagnostics explicitly use Lost Frame counters to investigate wiring, EMC and power-supply problems.[4][5]
If the counters keep increasing, inspect the physical layer: correct EtherCAT cable and connector, shield/PE, loose RJ45/M8/M12 contacts, moving cable chains, 24 V supply quality, long parallel routing beside motor cables and suspect device ports. A PLC/communication cable and a power cable solve very different problems.
Isolate the failing section instead of replacing everything
On a long line, identify the last healthy node and the first unhealthy one. Replace the suspect patch with a known-good cable; where the machine design permits it, compare the suspect SubDevice with a known-good equivalent or controlled bypass.
This is hypothesis testing, not random parts swapping. If the fault stays at the same port after the device is changed, the cable, upstream port or configuration becomes more likely. If the fault follows the device, the device or its parameters become stronger suspects.
Check ESI, Product Code and Revision after any hardware replacement
A network can have perfect physical link and still fail at PREOP/SAFEOP because the ESI file, Product Code, Revision, PDO set or startup parameters do not match the real replacement device. Similar-looking hardware revisions can expose different process-data or synchronization capabilities.
Do not stop at the product family printed on the front label. Compare the real identity data with the project. The device-integration and MainDevice–SubDevice communication guides explain this identity chain in more detail.
PDO / SyncManager problems often look like “link good, data bad”
A device can appear in topology and enter PREOP yet fail later because the configured PDO mapping, SyncManager size/direction or startup settings do not match what the device supports. Hand-edited PDOs, an old ESI or a project copied from a different revision are common ways to create this fault class.
Compare the configured process image with the device's real supported mapping rather than immediately restoring defaults. The EtherCAT technical specifications guide separates PDO, SyncManager and FMMU responsibilities.
A watchdog explains why outputs can drop while PLC logic still says TRUE
Many EtherCAT output devices implement a SyncManager watchdog. Beckhoff documents that the watchdog is reset by successful process-data communication; if valid EtherCAT process data is absent for the configured interval, the watchdog can trigger and outputs can be forced to a defined state.[6]
This explains the symptom “the PLC output is TRUE, but the valve/contactor dropped.” Check WcState, watchdog diagnostics and device state together. Increasing the watchdog time without finding the communication problem only delays the symptom.
A DC problem can exist even when the network is in OP
An EtherCAT network can be operational while synchronized servo motion or measurement still fails. Beckhoff separates FreeRun, SM-synchronous and DC-synchronous modes and documents diagnostic conditions such as Cycle Time Too Small, SM Event Missed, Shift Time Too Short and Sync Error where supported.[7]
Before replacing cables, verify the selected synchronization mode, SYNC0/SYNC1 period, shift time, MainDevice cycle and the device's minimum cycle time. The real-time performance and latency guides cover these timing layers.
If the network evidence is healthy, troubleshoot the application
If every device is OP, WKC is valid and lost-frame counters are stable, EtherCAT communication may not be the problem. Encoder scaling, 4–20 mA conversion, drive state machine, VFD controlword, NO/NC sensor logic or PLC application code can still be wrong.
For example, an encoder PDO can update correctly while the application assumes 8192 counts/rev instead of the real 4096. Or a drive can be in valid network communication but not complete its enable sequence. “Is EtherCAT healthy?” and “Is the machine function correct?” are separate tests.
Symptom-driven troubleshooting table
| Symptom | First evidence | Likely layer | First action |
|---|---|---|---|
| No SubDevices visible | MainDevice NIC/link | Wrong NIC/driver, first cable, first-node power | Verify NIC selection and first physical link |
| Everything after one node is missing | Topology + port LED | Cable, connector, intermediate port/power | Isolate boundary and compare with known-good cable/port |
| Stuck in PREOP | AL Status + identity | ESI/Revision/mailbox/startup configuration | Compare actual identity with the project |
| SAFEOP but not OP | AL Status + PDO/SM | PDO, SyncManager, watchdog, sync mode | Match ESI and real PDO/DC settings |
| OP but process data invalid | WKC / WcState | Frame loss or missing process-data participation | Inspect WKC and frame/port counters |
| Intermittent dropout | Error/lost-frame counters | EMC, moving cable, power, loose contact | Correlate counter growth with physical position/time |
| Servo synchronization error | DC/sync diagnostics | Cycle, shift, minimum cycle time | Verify sync mode and timing budget |
| Network healthy, machine wrong | OP + valid WKC | PLC logic, scaling, drive/sensor application | Trace process value to engineering units |
Verify the fix instead of stopping at “everything is green”
After the repair, clearing counters becomes useful. Run the machine for a defined period and confirm that lost-frame/error counters remain stable, every required node stays in OP, WKC remains valid, DC synchronization is stable where used and process values are fresh. Beckhoff's EtherCAT Simulation tool can deliberately create Lost Frames, Link Lost and Working Counter faults, demonstrating that the diagnostic path itself can be tested during machine validation.[8]
Document the symptom, time, AL Status, counters, changed component/setting and verification result. That record is much more useful on the next occurrence than relying on somebody remembering which cable was changed months ago.
Conformance reduces integration risk; it does not replace troubleshooting
Official EtherCAT conformance testing and CTT improve confidence that a device implementation follows the specifications. They cannot fix a damaged cable, EMC problem, wrong ESI, incorrect PDO or failed hardware in the field.[9]
The practical chain is conformant device + correct configuration + good physical installation + measurable diagnostics. OtomasyonAVM's power supplies, PLC/communication cables, sensors, servo systems, VFDs and SCADA sections make it possible to continue the diagnosis beyond the protocol page into the real field components.
Related EtherCAT and OtomasyonAVM guides
• What is EtherCAT?
• How does EtherCAT work?
• EtherCAT MainDevice–SubDevice communication
• EtherCAT topology
• EtherCAT device and sensor integration
• EtherCAT real-time performance
• EtherCAT latency
• EtherCAT technical specifications
• EtherCAT programming languages and tools
• EtherCAT limits and constraints
• Industrial communication
Technical references
[1] EtherCAT Technology Group — EtherCAT Diagnosis for Users: topology, Working Counter, link and physical-layer diagnosis. Diagnosis for Users
[2] Delta Motion — EtherCAT Diagnostics General tab: current/requested MainDevice and SubDevice states, software and hardware diagnostics. EtherCAT Diagnostics
[3] Beckhoff — WcState: valid/invalid cyclic communication and stale-input behavior. WcState
[4] Beckhoff — EtherCAT MainDevice frame statistics: cyclic/acyclic frame rates and lost/invalid frames. Frame Statistics
[5] Beckhoff — Lost Frame counter as an aid for wiring, EMC and power-supply diagnosis. Further Error Diagnostics
[6] Beckhoff — SyncManager watchdog behavior when valid EtherCAT process data is absent. Watchdog Notes
[7] Beckhoff — EtherCAT SubDevice synchronization modes and diagnostics including cycle/sync errors. Synchronization Modes
[8] Beckhoff — EtherCAT fault simulation for Lost Frames, Link Lost and Working Counter errors. Fault Simulation
[9] EtherCAT Technology Group — conformance testing and official EtherCAT Test Centers. Conformance