
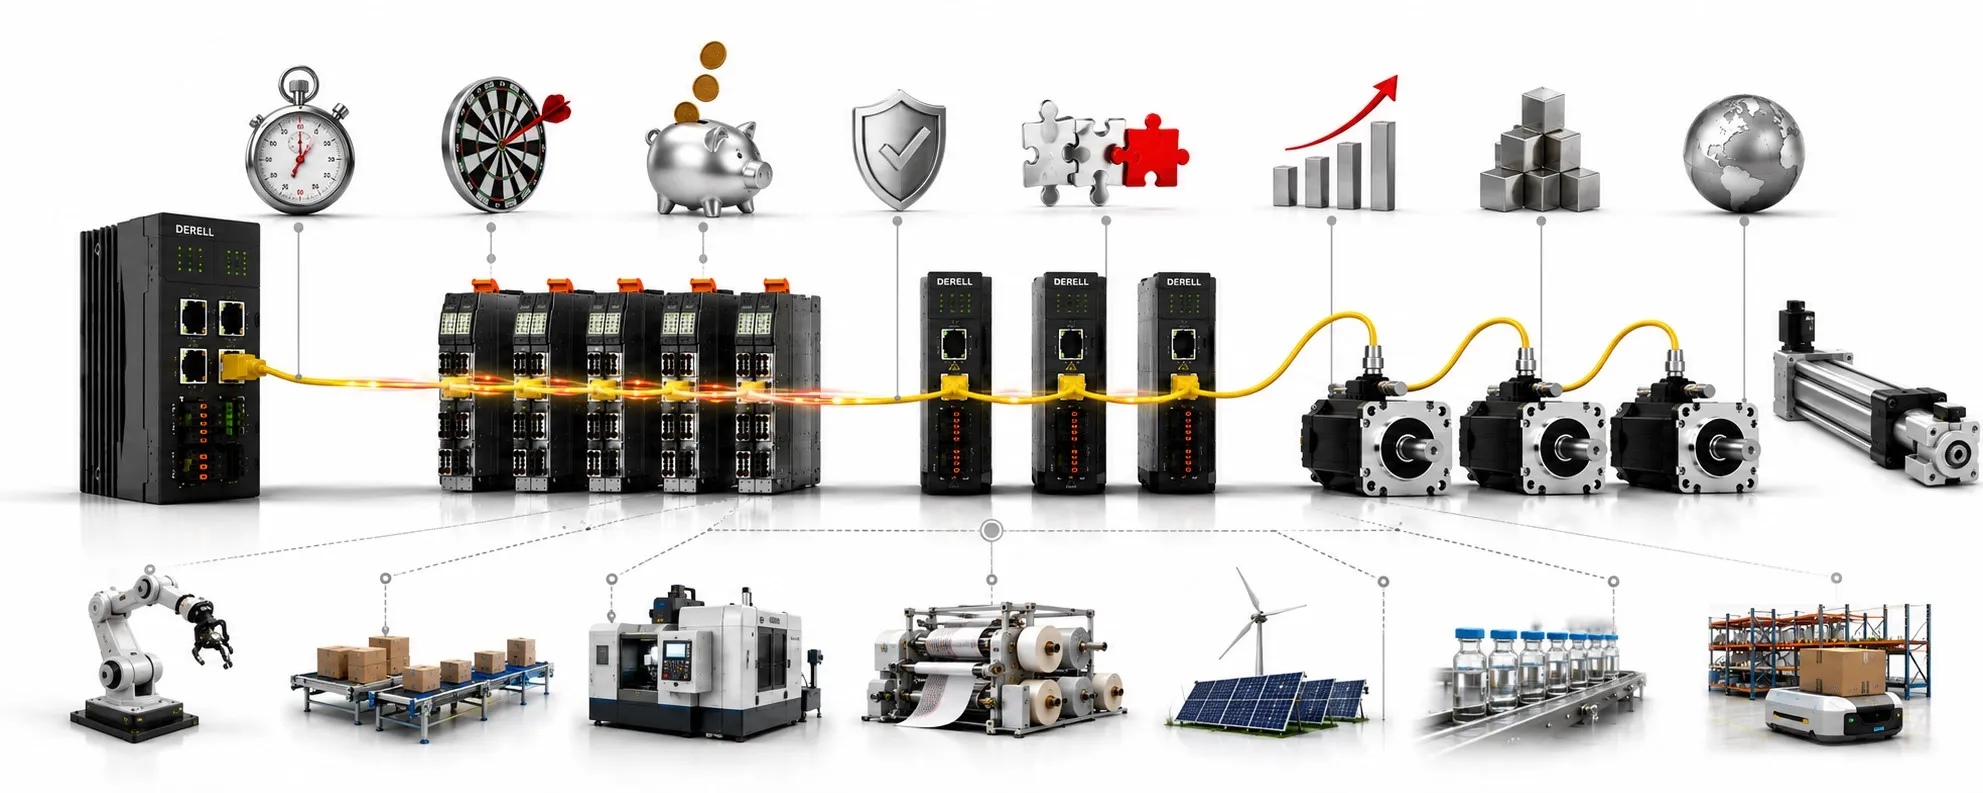
Why is EtherCAT used in industrial automation?
EtherCAT is selected most often where a machine needs distributed I/O, motion and measurement data to arrive not merely quickly, but predictably. Its industrial value comes from several mechanisms working together: efficient on-the-fly process-data handling, Distributed Clocks on devices that support them, flexible physical topology, detailed diagnostics, and the option to carry functional-safety data through FSoE. [1] [2]
That is a different question from simply listing EtherCAT's advantages. The engineering question is: which machine requirements make those features worth using?
1. The communication cycle should not become the machine's waiting time
A registration sensor on a packaging line, a synchronized press axis or a high-channel-count test stand does not just need “fast Ethernet.” It needs a timing budget in which cycle time, jitter and I/O response can be treated separately. EtherCAT uses MainDevice-controlled access and on-the-fly SubDevice processing to avoid the unpredictable medium-access delays associated with ordinary shared Ethernet behaviour. [2]
That is why EtherCAT is a natural candidate for motion, robotics, CNC, electronic-cam and fast-I/O applications where real-time behaviour matters. The 100 Mbit/s line rate, however, is not the response time of the machine. Sensor filtering, the drive control loop, PLC task timing and the mechanics still sit inside the end-to-end response.
2. Multiple axes can share a real time base
Coordinated motion is not solved by delivering commands quickly if each axis acts on a different notion of time. EtherCAT Distributed Clocks provide hardware support for synchronizing local clocks in compatible SubDevices to a shared system time. ETG documentation describes system jitter significantly below 1 µs in an appropriately implemented DC system. That is a mechanism and a capability—not a promise that every EtherCAT product automatically delivers the same synchronization quality. [3]
This matters in servo systems, industrial robotics, registration-controlled printing, flying saws and winding machines, where relative phase error between axes can become a product-quality problem. The feedback device—such as an encoder—and the local drive loop must still meet the same application timing budget.
3. It is designed for many small pieces of process data
Industrial control traffic is often made of hundreds of small values rather than large files: a limit-switch bit, a status word, a position value or a few analogue channels. EtherCAT lets multiple SubDevices read and insert their process data while the same frame moves through the network, reducing the packet-per-device overhead that would otherwise dominate small transfers. [2]
Beckhoff publishes example communication figures such as 1,000 digital I/Os in 30 µs and 100 servo axes every 100 µs. These are published platform examples, not universal field guarantees. They are still useful for showing the architectural reason EtherCAT fits dense PLC and distributed-I/O systems: the protocol is optimized for efficiently moving process data rather than creating a separate Ethernet conversation for every device. [4]
4. The network can follow the machine layout
A long conveyor, a four-module cartoner, a rotary table and a separate robot cell do not have the same geometry. EtherCAT supports line, tree, star and mixed topologies so the physical network can follow the machine rather than forcing the machine into a switch-centred layout. Many field connections also do not require separate Ethernet switches, which can reduce active infrastructure inside panels. [1]
This makes EtherCAT topology particularly useful in modular machines. Cable routing, replaceable sections, Hot Connect concepts and redundancy can be aligned with the mechanical structure. Ring cabling alone, however, is not a high-availability guarantee; the MainDevice and the actual configuration must support the intended redundancy behaviour.
5. Diagnostics can shorten the search for the failed layer
Once a machine is in production, downtime can cost more than the original network hardware. EtherCAT exposes evidence such as expected versus detected topology, device states, Working Counter results, link information and error counters. ETG explicitly treats diagnostics and precise fault localization as industrial benefits of the architecture. [1] [2]
The practical value is not simply a green “bus OK” lamp; it is the ability to distinguish a physical link problem from a missing SubDevice, invalid process data or an application issue. EtherCAT troubleshooting therefore deserves its own workflow. A bad Working Counter narrows the problem, but does not identify every root cause by itself.
6. Standard control and functional-safety communication can share the architecture
Safety over EtherCAT (FSoE) allows safety-related process data to use the EtherCAT communication medium. ETG states that FSoE was developed according to IEC 61508, is standardized in IEC 61784-3 and is suitable for safety applications up to SIL 3. [5]
That does not turn an ordinary EtherCAT product into a safety device, and functional safety is not the same as cybersecurity. A real safety function still requires certified safety components, the correct safety logic and parameters, machine risk assessment and validation. The design advantage is that standard control and safety communication can be integrated into the same field architecture when the required safety components are present.
7. A multi-vendor network is possible—but interoperability must be engineered
EtherCAT does not have to be a closed chain from one supplier. ETG's conformance system treats specification conformance as the prerequisite for devices from different vendors to cooperate in the same networked application, supported by the Conformance Test Tool, Plug Fests and official EtherCAT Test Centers. [6]
Still, two products carrying EtherCAT interfaces are not guaranteed to expose the same application features. The ESI file, profile support, PDO mapping, mailbox protocols, Distributed Clock modes and vendor-specific objects remain product-level checks. That is why device selection should follow the actual integration requirements described in EtherCAT device and sensor integration, not the connector shape alone.
8. MainDevice hardware can be simple—but “no special hardware is required” is too broad
One cost advantage is that the EtherCAT MainDevice can use a standard Ethernet MAC; ETG notes that a special MainDevice communication processor is not inherently required. That statement must not be extended to the field devices. A SubDevice needs EtherCAT controller functionality capable of processing the frame while it passes through. [2] [7]
So an ordinary Ethernet product does not become an EtherCAT SubDevice just because it has an RJ45 port. In a retrofit, existing sensors, drives and remote I/O may require native EtherCAT interfaces, a suitable gateway, or hardware replacement. The real licensing and cost structure therefore includes engineering, device compatibility and lifecycle support—not just cable and port prices.
9. Where do these reasons show up in real industries?
ETG lists EtherCAT deployments across robotics, machine tools, packaging, printing, plastics processing, presses, semiconductor equipment, test benches, pick-and-place systems, material handling, cranes and automated assembly, among many others. The list does not mean EtherCAT is mandatory in those sectors. What the applications tend to share is a need for distributed devices, short or predictable cycles, coordinated motion, modular wiring or detailed diagnostics. [1]
| Requirement | What EtherCAT contributes | What still needs verification |
|---|---|---|
| Coordinated multi-axis motion | DC-capable shared time base and short process cycles | Drive/device DC mode, local control loops and mechanics |
| Dense distributed I/O | Efficient process-data exchange through a shared frame | Total process image, I/O filters and actual MainDevice cycle |
| Modular machinery | Line/tree/star combinations and Hot Connect where supported | MainDevice features, ESI support and the real wiring plan |
| Shorter maintenance stops | Topology, state, link and WKC diagnostic evidence | Correct interpretation; a WKC error is not a complete diagnosis |
| Distributed functional safety | FSoE safety data over the common communication medium | Certified safety devices and machine-level safety validation |
| Multi-vendor machine | ETG conformance ecosystem and common protocol | Profiles, ESI, PDOs, mailbox services and optional features |
Worked selection example: a modular 12-axis packaging line
Consider a hypothetical machine with 12 servo axes, four remote-I/O islands, registration sensors, analogue pressure and temperature measurements, and several guarded access points. The engineering case for EtherCAT is more specific than “100 Mbit/s is fast”: the axes can use a shared timing framework, the machine modules can be reflected in the topology, drive and I/O process data can share the same cyclic exchange, diagnostics can narrow a failed section, and—if certified safety hardware is selected—FSoE can fit into the same field architecture.
Now compare that with an isolated tank station containing four digital inputs, two analogue measurements and a process that only needs updates every few seconds. Most of EtherCAT's timing and synchronization capabilities may add little value there. Existing controller infrastructure, maintenance skills, spare-parts policy and total lifecycle cost may dominate the decision. The industrial goal is not to choose the fastest protocol; it is to choose the network whose timing, topology, diagnostic and lifecycle behaviour matches the machine.
Bottom line: EtherCAT earns its place in industry when a project genuinely benefits from deterministic process exchange, synchronized motion, efficient distributed I/O, topology freedom, useful diagnostics, integrated functional-safety communication and a broad device ecosystem. If those requirements are absent, the choice should be challenged rather than justified by the EtherCAT name alone.
Technical references
[1] EtherCAT Technology Group — Why use EtherCAT?: performance, topology, diagnostics, cost considerations and application areas. ethercat.org/en/why_use_ethercat.htm
[2] EtherCAT Technology Group — EtherCAT Technology / Implementation: on-the-fly processing, MainDevice/SubDevice roles, standard MAC use and real-time behaviour. ethercat.org/en/technology.html
[3] EtherCAT Technology Group — Distributed Clocks: hardware-supported DC synchronization and shared System Time. ETG Distributed Clocks
[4] Beckhoff Automation — EtherCAT Highlights: published performance examples, topology and diagnostic features. Beckhoff EtherCAT Highlights
[5] EtherCAT Technology Group — Safety over EtherCAT (FSoE): IEC 61508, IEC 61784-3 and safety applications up to SIL 3. ethercat.org/en/safety.html
[6] EtherCAT Technology Group — Conformance: specification conformance, CTT and EtherCAT Test Center approach to interoperability. ethercat.org/en/conformance.html
[7] EtherCAT Technology Group — FAQ: standard Ethernet controller use on the MainDevice side, cost considerations and implementation distinctions. ethercat.org/en/faq.html