
What are the technical specifications of EtherCAT?
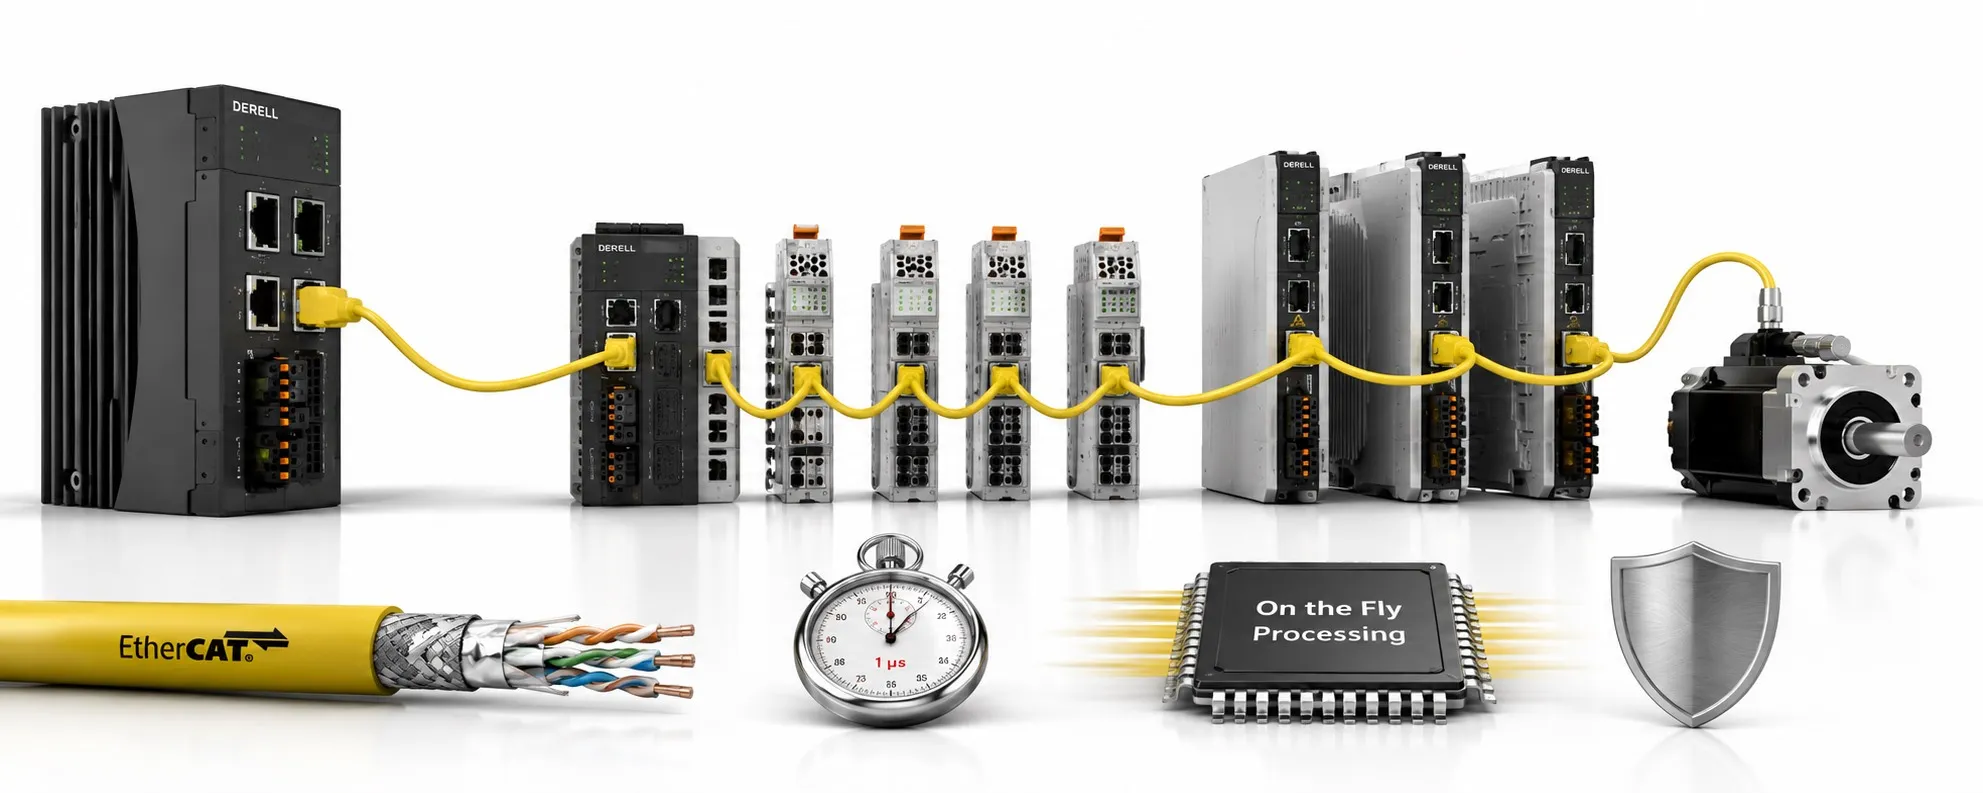
What are the technical specifications of EtherCAT? A useful EtherCAT specification sheet has to separate four things that are often mixed together: wire speed, network cycle, clock synchronisation and device processing time. Classic EtherCAT normally runs over 100BASE-TX at 100 Mbit/s full duplex, but its real-time behaviour comes from the way EtherCAT frames are processed by SubDevices, not from the Ethernet bit rate alone. The protocol combines on-the-fly frame handling, a logical process image, hardware-assisted timing and a defined device state machine.[1]
This page therefore treats the specification as an engineering reference rather than a list of marketing numbers. For the basic concept first see what EtherCAT is; for a frame-by-frame explanation see how EtherCAT works.
| Item | Engineering reference | Important qualification |
|---|---|---|
| Classic line rate | 100 Mbit/s, full duplex, commonly 100BASE-TX | Line rate is not the machine cycle time |
| EtherCAT frame ID | Standard Ethernet frame, EtherType 0x88A4 | Cyclic EtherCAT data does not require a normal TCP/IP stack |
| Copper link | Up to 100 m between two nodes in 100BASE-TX | This is not a 100 m limit for the entire EtherCAT network |
| SubDevice address field | 16 bit; theoretical scale up to 65,535 SubDevices | Practical size depends on controller, data volume and cycle requirements |
| Distributed Clocks | Hardware-assisted clock synchronisation; jitter can be well below 1 µs | The individual device must actually support and be configured for DC |
| Device description | ESI XML plus SII information in the device | An Ethernet connector alone proves no EtherCAT compatibility |
The physical layer comes first, but it does not define the control performance
A classic EtherCAT segment commonly uses 100BASE-TX, 100 Mbit/s full duplex. ETG installation guidance also covers 100BASE-FX fibre and LVDS backplane links. With copper 100BASE-TX, the point-to-point distance between two EtherCAT devices is up to 100 m. Fibre can extend a link much further, but the permitted distance has to be taken from the actual optical interface or product documentation.[2]
That distinction matters when reading an Ethernet cable-length specification. A 100 m copper link limit does not mean that a line of many EtherCAT devices is limited to 100 m end-to-end. Each compliant active link is evaluated separately.
The frame: ordinary Ethernet envelope, EtherCAT-specific payload
EtherCAT embeds its payload in a standard Ethernet frame. Direct EtherCAT frames use EtherType 0x88A4. Inside that frame are one or more EtherCAT datagrams, and each datagram carries its own command, addressing information, payload and Working Counter. Because the MainDevice can group access to many SubDevices into the same frame, small I/O values do not each need a separate Ethernet packet.[1]
The MainDevice can use a standard Ethernet MAC. The field device is different: a SubDevice requires an EtherCAT SubDevice Controller (ESC) or an equivalent EtherCAT implementation to process relevant bytes while the frame is passing. This is why a standard communication port or RJ45 socket must never be treated as evidence that the device is an EtherCAT SubDevice.[1]
Logical addressing is what makes a distributed process image practical
For cyclic process data, EtherCAT can address a logical process image instead of issuing an individual high-level request to every device. The FMMU maps parts of that logical address space onto local SubDevice memory and can work down to bit granularity. ETG describes a 4 GByte logical address space; this is an addressing space, not a claim that gigabytes of I/O are transferred every control cycle.[3]
This is especially useful in systems combining PLCs, distributed I/O, servo systems and high-resolution encoders. The process image can be organised for the control task rather than mirroring a simple “device 1, device 2, device 3” cable order.
SyncManagers protect the handover between network memory and the local application
FMMUs and SyncManagers solve different problems. FMMUs establish where data appears in the EtherCAT logical process image. SyncManagers coordinate access between the ESC memory and the local device application. A common arrangement uses SM0/SM1 for mailbox traffic and SM2/SM3 for output and input process data. This mechanism allows the network side and the application side to exchange consistent data without treating the ESC RAM as uncontrolled shared memory.[4]
Distributed Clocks define timing quality independently of the raw bit rate
EtherCAT's Distributed Clocks (DC) synchronise device clocks to a reference clock and compensate for propagation delays. ETG documents system jitter significantly below 1 µs for correctly implemented DC systems. That capability is one reason EtherCAT is widely used in coordinated motion, but the network's clock quality should not be confused with the internal sampling or control-loop bandwidth of a drive or sensor.[1]
In a motion application, the engineer still has to check the drive's supported synchronisation mode, minimum cycle time and the MainDevice task schedule. The separate pages on real-time performance and EtherCAT latency address those timing questions in more detail.
Startup is governed by the EtherCAT State Machine
An EtherCAT SubDevice normally moves through INIT, PREOP, SAFEOP and OP; BOOT is optional. The states describe what the device is allowed to do. PREOP enables mailbox communication but not normal process-data exchange. SAFEOP can provide valid inputs while outputs remain in a safe state. OP is the normal state in which valid output process data can be applied by the device.[5]
This makes the state machine a diagnostic tool as well as a startup sequence. A device that reaches SAFEOP but refuses OP may be telling you far more than “network fault”: PDO configuration, SyncManager settings, watchdog timing, Distributed Clock configuration or a device-specific application condition may be blocking the transition. See EtherCAT fault detection for a troubleshooting-oriented treatment.
Working Counter adds transaction-level validation
Each EtherCAT datagram ends with a 16-bit Working Counter (WKC). SubDevices that actually perform the addressed operation contribute to that counter according to the command type. The MainDevice compares returned WKC values with the expected result. An unexpected WKC therefore indicates that the intended data access was incomplete, even if the Ethernet frame itself returned to the controller.[6]
WKC should not be treated as a magic “faulty node number”. It tells the controller that the expected participation in a datagram did not occur. Locating the cause still requires topology, port status, device state and configuration diagnostics. A SCADA or HMI value can also remain visible after communication has become invalid, so application-level data-age checks remain important.
ESI and SII turn a generic network into a configured machine
ESI (EtherCAT SubDevice Information) is the XML-based device description supplied for an EtherCAT SubDevice. It describes network-accessible properties such as process data, mapping options, mailbox protocols, synchronisation capabilities and physical ports. The device's non-volatile SII stores identity and basic functionality information that can be read during startup.[7]
This is why device revision matters. Two drives with the same front-panel connector can expose different PDOs, object dictionaries or synchronisation modes. When selecting EtherCAT devices and sensors, the actual ESI/device manual is stronger evidence than appearance or connector type.
Mailbox protocols extend EtherCAT beyond cyclic I/O
EtherCAT supports mailbox-based application protocols for configuration and services. CoE carries CAN application protocols such as CANopen-style object dictionaries and profiles over EtherCAT; it does not turn the physical network into CAN. FoE supports file transfer, EoE transports conventional Ethernet traffic through EtherCAT mailbox channels, and SoE supports the servo-drive profile associated with IEC 61800-7. Availability is device-specific, not universal.
Engineers working with drive object dictionaries may therefore benefit from the separate CANopen guide, while motion-specific implementation should be verified against the actual servo manual rather than assuming that every servo drive exposes the same EtherCAT profile.
Topology is flexible, but redundancy is a configured feature
Lines, trees, branches and stars are possible without inserting a conventional Ethernet switch between every pair of devices. Junction devices can create branches and the full-duplex return path is part of normal EtherCAT operation. Cable redundancy and Hot Connect can also be implemented, but they require the appropriate MainDevice, hardware and configuration; they should not be described as automatic properties of every EtherCAT installation.[1]
For network-layout choices see EtherCAT topology. When comparing the layout with conventional switched Ethernet, keep the distinction from switch and hub behaviour clear.
What does “65,535 nodes” actually mean?
The EtherCAT SubDevice address field is 16 bit, and ETG documentation describes a theoretical network scale of up to 65,535 SubDevices. That is an addressing capability. It is not a promise that a controller, engineering tool or real-time task can operate 65,535 devices with any chosen cycle time. Process data size, number of datagrams, controller memory, configuration limits and the target cycle all determine the usable network size.[2]
This is one of the reasons the limits and constraints of EtherCAT deserve a separate discussion rather than being hidden inside a specification table.
A small process-image example
Example, not a measured machine: suppose 12 servo axes are mapped with 16 bytes of MainDevice-to-drive RxPDO data and 16 bytes of drive-to-MainDevice TxPDO data per axis. The application process-image requirement is 12 × (16 + 16) = 384 bytes. At 100 Mbit/s, the raw serialization time of 384 bytes alone is about 30.72 µs. That figure is deliberately not called the EtherCAT cycle time. Ethernet/EtherCAT headers, datagram overhead, WKC, propagation delay, ESC forwarding, MainDevice execution and each device's local sampling/processing remain outside that simple byte calculation.
This is a better way to read a specification than saying “100 Mbit/s therefore the machine updates in X microseconds.” The advantages of EtherCAT come from the complete architecture, not from one headline number.
EtherCAT G and G10 are extensions, not a silent speed change
Classic EtherCAT remains a 100 Mbit/s technology. EtherCAT G raises the rate to 1 Gbit/s and EtherCAT G10 to 10 Gbit/s. ETG's branch concept lets high-speed trunks coexist with established 100 Mbit/s EtherCAT segments, and branch controllers can process connected segments in parallel. A 100 Mbit/s SubDevice does not become a gigabit device merely because the machine contains an EtherCAT G backbone.[8]
The distinction is important when reading EtherCAT generations and extensions. Compatibility, branch topology and MainDevice port capability need to be checked rather than assuming one universal link speed.
EtherCAT P adds power to the communication system
EtherCAT P combines EtherCAT communication and power in a dedicated cabling/connector system. It is a physical-layer extension, not a software option that can be enabled on every ordinary EtherCAT socket. Connector type, current budget, cable length and voltage drop are part of the design.[9]
FSoE is functional safety communication, not general cybersecurity
Safety over EtherCAT (FSoE) is the functional-safety communication layer associated with IEC 61784-3 CPF 12. It can carry safety-related communication over the same underlying EtherCAT system, but it does not replace authentication, network segmentation, access control or other industrial cybersecurity measures. Likewise, the presence of FSoE does not by itself establish the SIL of the complete machine.[10]
Standards position
EtherCAT is specified internationally as IEC 61158 Type 12 and as CPF 12 in IEC 61784-2. Related standards cover areas such as drive profiles and functional safety. This standardisation describes communication technology; it should not be used as shorthand for complete machine compliance, EMC compliance or product safety certification.[11]
For an engineering decision, combine the specification above with the actual SubDevice ESI/manual, MainDevice limits, required cycle time and the machine's safety and diagnostic concept. The related pages on MainDevice/SubDevice communication, other Industrial Ethernet protocols and industry standards cover those neighbouring questions without repeating this specification page.
Related EtherCAT guides
References
[1] EtherCAT Technology Group, EtherCAT Technology: ethercat.org/en/technology.html
[2] EtherCAT Technology Group, ETG.1600 EtherCAT Installation Guideline: ETG.1600 Installation Guideline
[3] EtherCAT Technology Group, logical addressing and FMMU: EtherCAT Implementation
[4] EtherCAT Technology Group, ESM / SyncManager: ESM Knowledge Base
[5] EtherCAT Technology Group, EtherCAT State Machine: INIT, PREOP, SAFEOP, OP
[6] EtherCAT Technology Group, EtherCAT Diagnosis for Users: Working Counter diagnostics
[7] EtherCAT Technology Group, EtherCAT SubDevice Information (ESI): ETG.2000 / ESI resources
[8] EtherCAT Technology Group, EtherCAT G: Gigabit levels and branch concept
[9] EtherCAT Technology Group, EtherCAT P: EtherCAT P technology
[10] EtherCAT Technology Group, Safety over EtherCAT: FSoE / IEC 61784-3 CPF12
[11] EtherCAT Technology Group, international standardisation: IEC 61158 Type 12 / IEC 61784-2 CPF 12