
Torque control with servo motors?
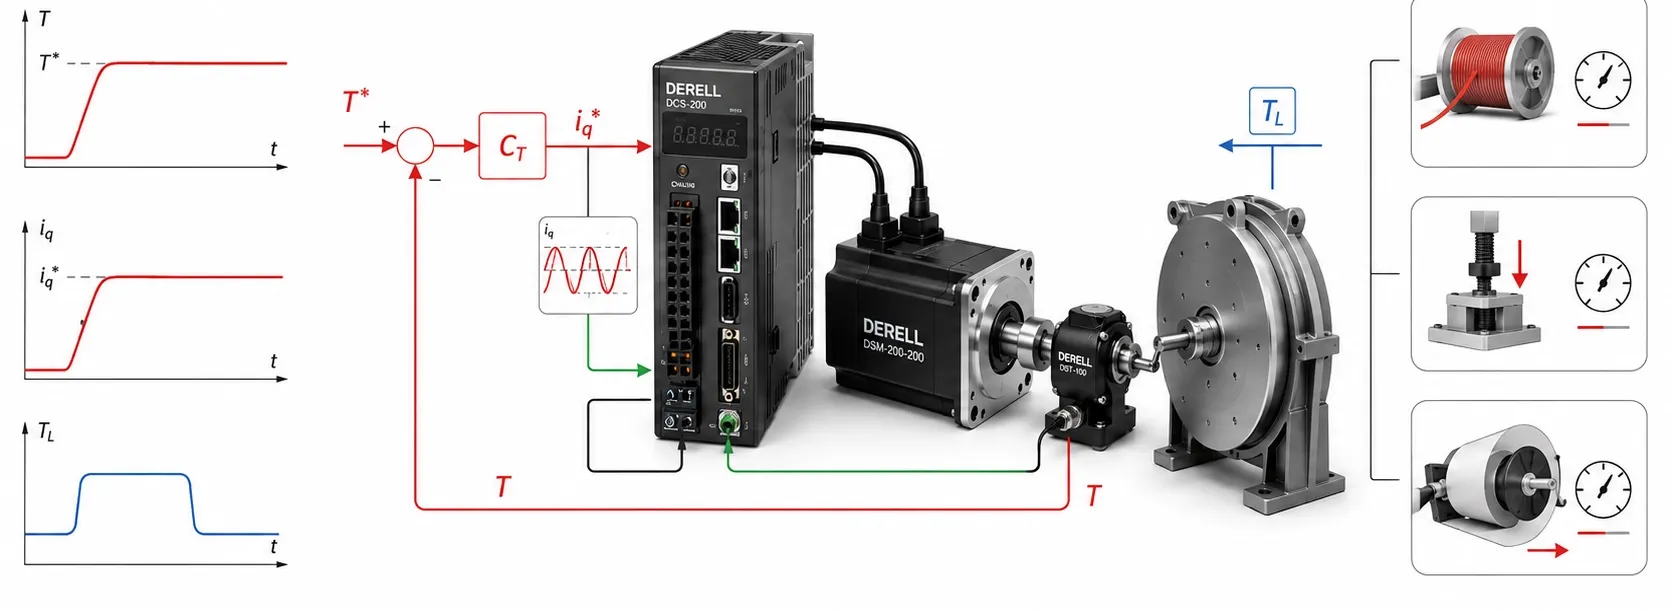
Matching motor torque to the load
Servo torque control regulates the motor's turning moment according to a command. The objective is not always to reach a particular position or maintain a constant speed; an application may need controlled material tension, limited pressing force or assistance to another axis. In a servo system, the drive achieves this by regulating motor current rapidly. Torque is measured in N·m; it is not the same quantity as motor power or linear force.
How does the drive regulate torque?
For a typical permanent-magnet AC servo, the drive measures phase currents and uses the rotor's electrical angle to regulate the torque-producing current component. This is associated with field-oriented control, or FOC, an approach used in vector control. The inner current loop compares commanded and measured currents, then adjusts power-stage switching. Consequently, implementing torque control involves more than simply applying a higher voltage to the motor.
An encoder or resolver provides rotor position information; the drive can also derive speed from this information. These devices do not measure torque directly. The drive's “actual torque” display is usually calculated from current and motor parameters. Independent measurement of actual shaft torque requires a torque transducer; when measuring torque, the measurement point must also be identified, for example the motor shaft or gearbox output.
Torque mode and torque limiting serve different purposes
In torque mode, torque is the main command; speed and position can change as the load responds. If the opposing load suddenly decreases, the same torque can accelerate the motor. Positive and negative speed limits and stopping behaviour therefore need to be configured using functions supported by the drive. At a speed limit, the drive may reduce torque, so commanded torque and constant speed cannot both be maintained under every condition.
Torque limiting restricts the available torque while a speed or position controller remains active. Asking an axis to “run at 1,000 rpm without exceeding 2 N·m” differs from commanding 2 N·m directly. If the load requires more torque, speed may fall or position error may increase. This distinction is central to speed, torque and position control and to comparing speed control with torque control.
Current, torque constant and operating limits
A simplified relationship is T ≈ Kt × I, where I must use the current definition associated with the torque constant. For a hypothetical motor with Kt = 0.8 N·m/A RMS, producing 2 N·m of electromagnetic torque requires approximately 2.5 A RMS. RMS current, peak current and the drive's internal q-axis scaling must not be mixed. Motor design, temperature, saturation and field weakening can affect the relationship, so it is not a perfect shaft-torque measurement under all conditions.
Continuous torque, short-duration peak torque and drive current capability must be considered together. A motor that delivers 2 N·m continuously and 6 N·m briefly cannot necessarily operate at 6 N·m indefinitely. The torque-speed curve, ambient temperature and duty cycle establish how torque affects motor selection. The difference between torque and power also matters: mechanical output power is zero at zero speed, but producing holding torque still requires current and heats the motor.
Two practical distinctions in winding and force applications
For a winding application, ignoring losses and acceleration gives T = F × r. Maintaining 100 N of material tension requires 5 N·m at a 50 mm radius and 10 N·m at a 100 mm radius. Keeping torque at 5 N·m as the radius doubles reduces tension to 50 N. Therefore, constant torque does not mean constant material tension; diameter calculation or force feedback may be required.
In pressing and clamping applications, motor torque becomes force through the transmission mechanism. Gearbox selection, screw lead, efficiency and friction affect the result. For example, a 10:1 gearbox with 90% efficiency produces approximately 9 N·m at its output from 1 N·m at the motor in a simplified calculation. Treating motor torque as the force applied to a part without calculating the load and transmission is incorrect. Precise force control may require an outer loop using a load cell.
Command sources and the outer control loop
Depending on the drive, the torque reference can come from an analogue input, a communication interface or a motion controller. A compatible EtherCAT system may support cyclic synchronous torque, or CST, but being an EtherCAT servo does not guarantee every torque function. Check whether the command represents N·m or a percentage of rated torque, its sign and scaling, and the response to a communication loss.
When the actual process target is tension or pressing force, an outer loop in PID control with a servo can compare measured force with its target and generate the torque reference. The drive's fast inner current loop continues operating. Poor handling of outer-loop saturation, integral windup or mode transitions can cause oscillation or abrupt movement.
What should be checked during commissioning?
After selecting a suitable servo motor and drive, verify motor identification, feedback direction, torque sign and command scaling. During low-limit trials following the manufacturer's procedure, monitor the torque reference, calculated torque, speed and position together. A torque ramp can reduce the mechanical effects of sudden torque increases, but an excessively slow ramp can also impair process response. Correct torque control is demonstrated by the system's response to load changes as well as its ability to reach a setpoint.
Related servo topics
Servo fundamentals, speed, torque and position control, servo motor and drive selection, load and transmission calculations, PID control with a servo and EtherCAT servo systems.
Measurement and other related categories
Encoders, resolvers, torque transducers, gearbox selection, speed versus torque control and torque control in motor drives.