
Servo drive and motor relation
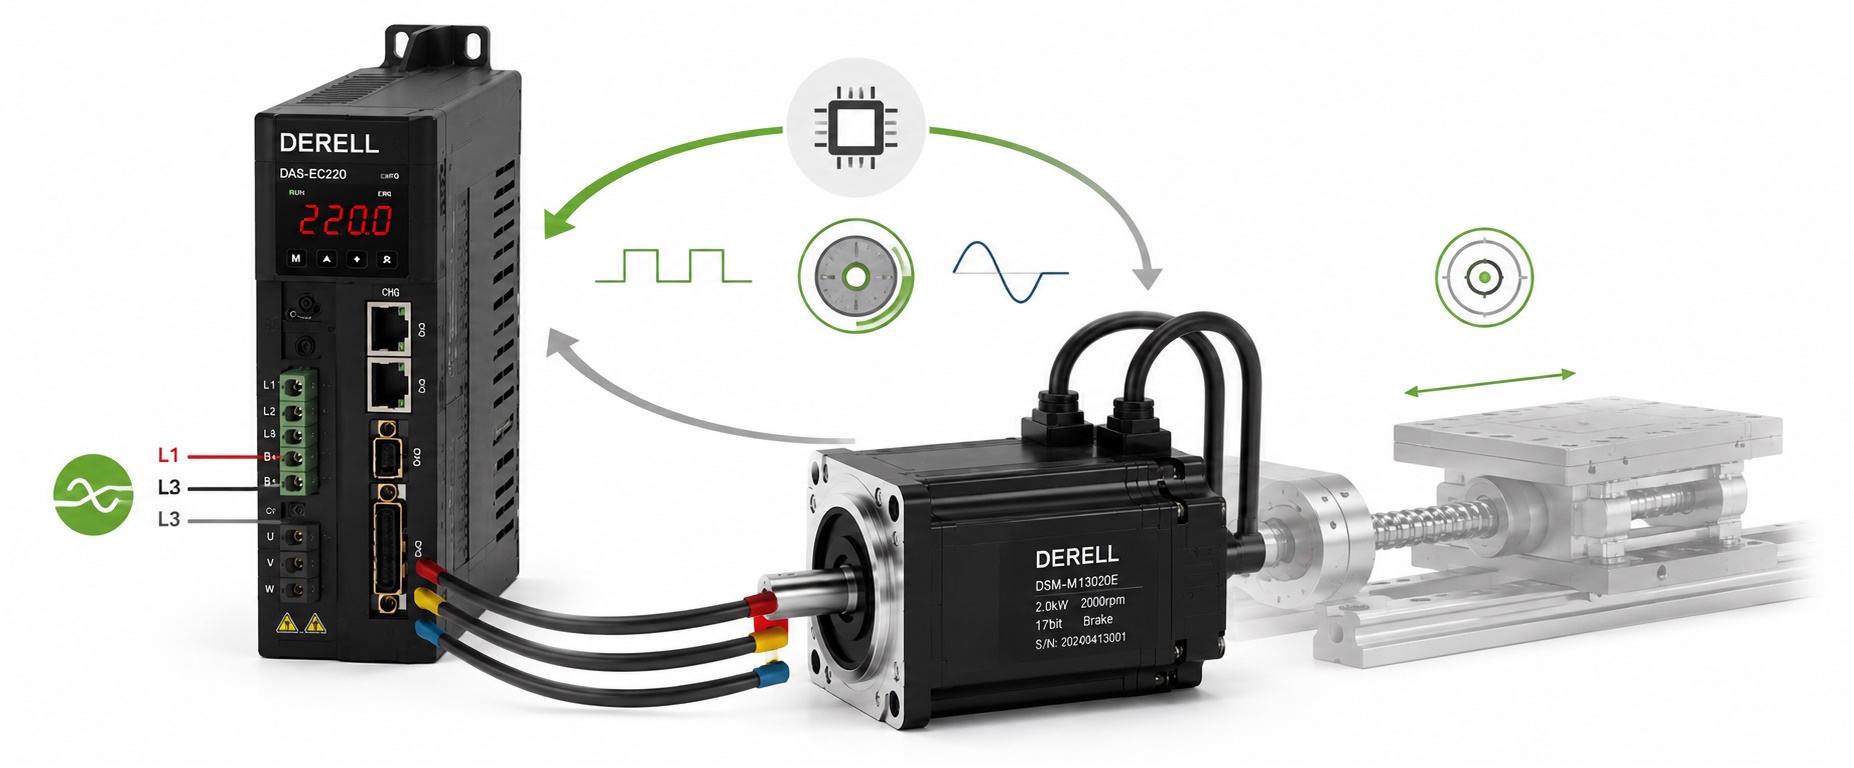
A servo drive turns a motion request into controlled electrical power for a servo motor. The controller specifies the move, the drive regulates motor current, and an encoder or resolver reports what the axis actually did. Together they provide closed-loop control of position, speed or torque, depending on the operating mode.
Watch an axis move to 90°
The example uses a fixed 90° target. The blue pointer shows actual shaft position; the dashed line marks the destination. Select Start / replay to see the shaft move and position information return to the drive. Stop holds the illustration at its current point.
Position error = target position − measured position. At the illustrated checkpoints, the readings are 0° with 90° error, 60° with 30° error, 85° with 5° error, and 90° with zero error. The motion is slowed down and paused for teaching; it is not a realistic servo trajectory. In a working positioning axis, the target typically follows a planned motion profile rather than jumping directly to its final value.
Three paths with different jobs
Command path: A PLC, CNC or motion controller supplies the setpoint. Depending on the drive, this may use pulse and direction, an analogue reference, or a network such as EtherCAT. Check the supported interface; a drive does not automatically accept every command format.
Power path: The drive's switching power stage applies controlled voltage and current to the motor windings using energy from its supply. A low-power command signal does not itself power the motor. For torque control, the torque-producing current component is approximately proportional to torque within the relevant operating range.
Feedback path: An encoder or resolver provides rotor position information; speed can be derived from how that position changes over time. An encoder is not a torque sensor. The current loop uses current measurements inside the drive. Measuring actual load torque directly requires a suitable additional sensor.
Why a servo uses several control loops
A typical cascade starts with a position loop that requests speed. The speed loop then requests current or torque, and the faster inner current loop regulates the motor current. Position, speed and torque modes therefore use different parts of the control structure. The difference between speed and position control matters when choosing an operating mode.
The loops may be split between the controller and drive. Nor is every servo simply a single PID block: implementations can use P or PI controllers, feedforward and filters. Appropriate drive configuration and tuning help the axis achieve the required dynamic performance without excessive oscillation.
At the target, the drive still has work to do
Zero speed does not imply zero current. An axis holding position against a load can produce torque, draw current and generate heat even with very little position error. A disturbance prompts the control system to correct the motion, within the limits of the motor, drive and mechanism.
Positioning accuracy also depends on mechanics. Gearbox backlash, coupling flexibility, load inertia and feedback noise all matter. A motor encoder can report the correct shaft angle while backlash leaves the driven load displaced. More encoder counts alone cannot fix that mechanical error.
Choosing a motor and drive that work together
Match the motor and drive by supply voltage, continuous and peak current, motor technology, feedback protocol, pin assignments and motor parameters. A matching kW rating or connector shape is insufficient. Permanent-magnet motors also need the correct electrical rotor angle and phase relationship for commutation.
Use the motor selection criteria alongside load inertia and transmission calculations. During maintenance, inspect power and feedback cables, connectors and mechanical connections. Check how the system handles deceleration energy through regenerative braking; a drive may dissipate this energy rather than return it to the mains.
Technical references: Kollmorgen — control loops · Beckhoff — servo control technology · Kollmorgen — tuning guide · Kollmorgen — power conversion and feedback · Kollmorgen — commutation and phase alignment