
Advanced Control Approaches in Servo Systems
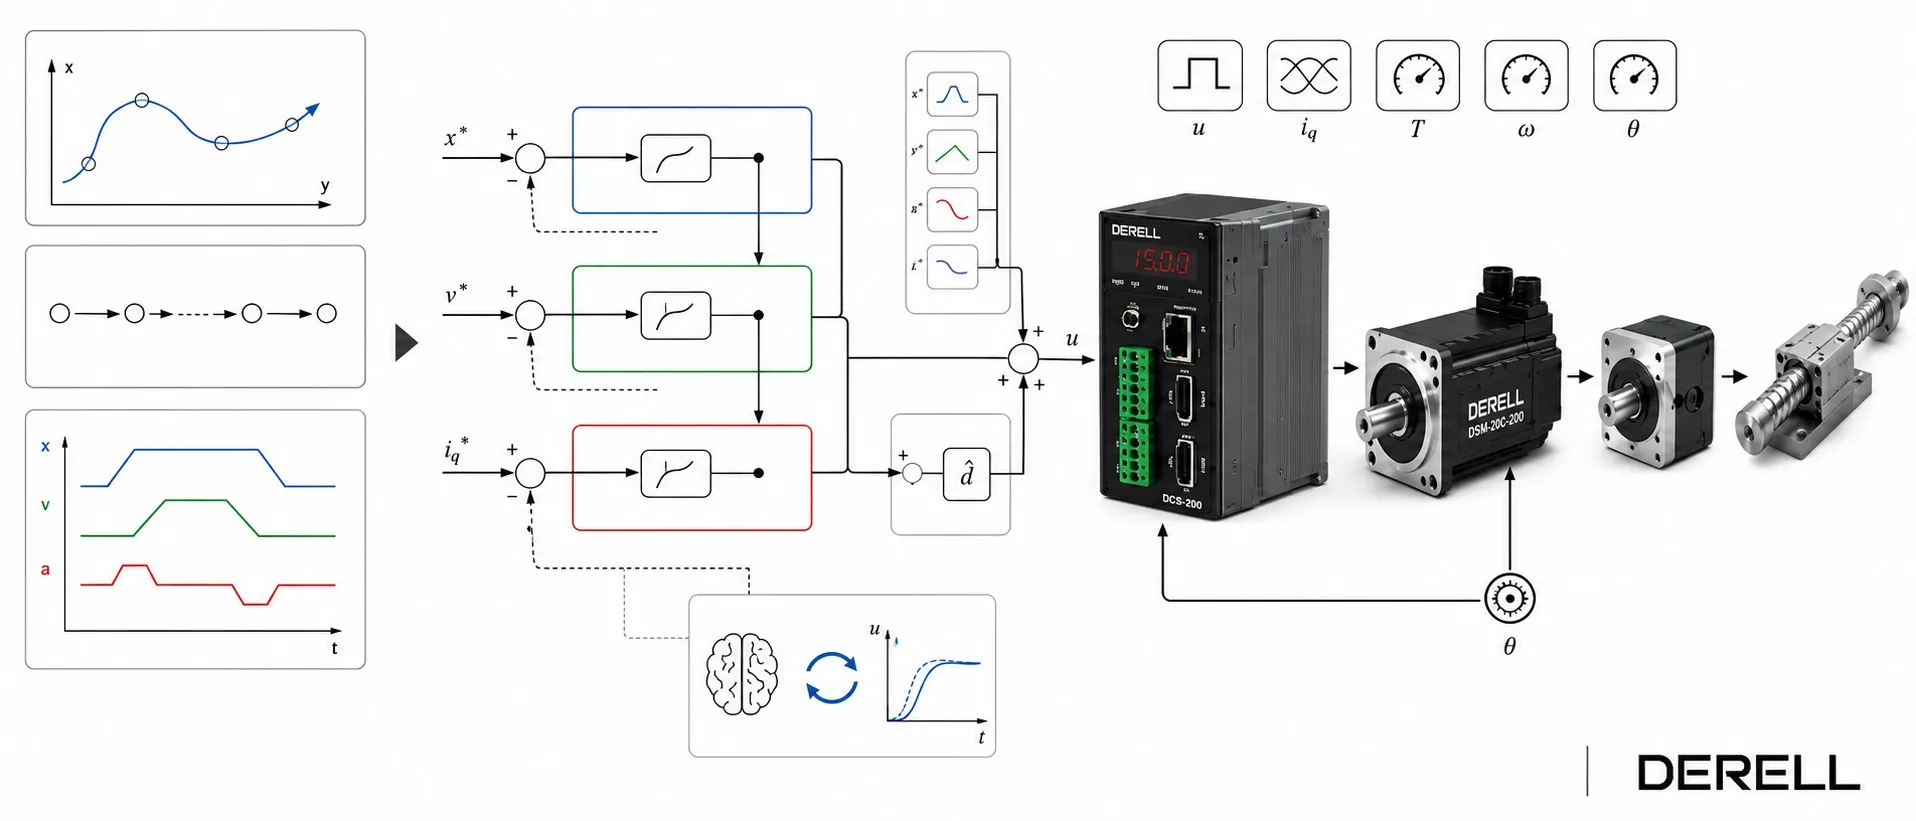
Advanced Servo Control: Tuning for the Actual Machine
A powerful servo motor can still overshoot, chatter or take too long to settle. Useful performance comes from matching the motor, drive, feedback and mechanics, then adjusting their response to the job. Drawing on Advanced Motion Controls (AMC) technical resources, this guide explains loop tuning, smooth starts, low-speed motion and regenerative energy.
Understand which loops are doing the work
In a common cascaded arrangement, the position loop requests velocity, the velocity loop requests current or torque, and the inner current loop regulates motor current. Not every axis uses all three loops, and an external motion controller may close some of them.
| Loop | Everyday question | Signals to compare |
|---|---|---|
| Current | How hard should the motor work? | Commanded and measured current |
| Velocity | How fast should the axis move? | Commanded and measured velocity |
| Position | Where should it finish? | Target and measured position |
The tuning requirements for torque mode differ from those for velocity or position control. For the loops used by the selected architecture, the usual order is current, velocity, then position. Follow the product's commissioning sequence for motor identification and commutation.
Separate the motion command from the response
Trajectory planning defines the acceleration and deceleration you ask for. Tuning determines how closely the axis follows that request. Acceleration changes velocity; jerk changes acceleration. A suitable S-curve or jerk limit can reduce abrupt mechanical loading at the start and end of a move. Reducing the current limit is a different adjustment.
Depending on the operating mode, the drive or an upstream controller generates the trajectory. Smoother transitions may take longer, so assess dynamic performance against both cycle time and mechanical demands.
Measure the result instead of judging it by sound
Overshoot means passing the target. Settling time is the time needed to enter a specified error band and remain there. Whining, oscillation, high current and following errors can point to poor tuning, but also check mechanical vibration, wiring, commutation, feedback and friction. A compact machine is not automatically a low-inertia or easy-to-tune system.
Illustrative example: An axis commanded to 100.00 mm reaches 100.60 mm before returning. Its overshoot is 0.60 mm. A revised setting that reaches the target 0.10 seconds earlier but oscillates for longer may make the complete cycle worse. Plot target and actual position together, and assess following error, settling time and current. These numbers explain the concept; they are not AMC product test results.
Choose the tuning tools that match the drive
Auto-tuning can provide a useful starting point where supported. AMC's ACE environment offers automatic loop tuning on selected FlexPro models. DriveWare provides measurement and configuration tools for compatible digital drives. AxCent analog drives may use hardware adjustments such as DIP switches and potentiometers, depending on the model. These are different commissioning workflows.
For manual refinement, change one parameter and repeat the same test so the effect is clear. Feedforward uses information from the requested motion to help reduce tracking lag; it does not replace a stable feedback loop. After automatic setup, validate the response with the actual load and required velocity, torque and position modes.
Treat low-speed motion as its own test
At very low speeds, friction, motor cogging and feedback resolution can become more noticeable. Increasing gain is not always the answer. Tools such as AMC's Low Speed Smoothing, where supported, can improve low-speed behavior. Filtering reduces measurement ripple but also changes the control response. A quieter trace does not automatically mean a better axis. Confirm model support before assuming that friction or cogging compensation is available.
Give braking energy somewhere to go
During deceleration, or when the load drives the motor, mechanical energy can return to the electrical system. Without a suitable path for this regenerative energy, DC bus voltage rises and the drive may trip on overvoltage. The relevant factors are returned energy, bus capacitance and supply behavior, rather than machine size alone.
A compatible shunt regulator or braking circuit can dissipate surplus energy as heat in a resistor. AMC offers drives with internal shunt circuitry and external shunt options. Check bus voltage, clamping threshold, peak energy and average power. Sharing energy across a common bus or returning it to the mains requires an appropriate system design. Electrical braking and a mechanical holding brake serve different purposes.
Validate the complete operating envelope
Confirm motor data, feedback settings, current limits, mechanical connections and travel limits before testing. Keep the test movement within the machine's permitted travel and load conditions. Record command, actual motion, current and bus voltage at light and heavy loads, in both directions, at low and high speeds, and through repeated stops. Changes to sizing parameters or gearbox characteristics call for another validation of the existing settings.
A useful acceptance test shows that the axis meets its accuracy and cycle-time requirements without excessive oscillation, unnecessary current or recurring faults. Save the parameter file together with the test conditions. Smooth unloaded rotation is only part of the evidence.
Advanced Motion Controls (AMC) — official products and technical resources
Explore AMC's drive families and accessories on the Advanced Motion Controls servo drives page. Use the current documentation for the selected model to confirm features, compatibility and commissioning procedures.
Technical reading: Loop tuning · FlexPro auto-tuning · ACE user guide · DriveWare quick reference · AxCent analog drives · Shunt regulation · Power supply sizing · Installation and tuning mistakes.